Humanoid robotics
Human-inspired mechanisms, integrated actuation and control architectures for capable, coordinated movement.
HYDROïD · ROMEO2PROFESSOR · RESEARCHER · INNOVATOR
Full Professor at Evry, Paris-Saclay University
Mechatronic systems, humanoid robotics and assistive technologies developed through research, teaching and industrial collaboration.
“Intelligent
Mechatronics in the
service of humanity”
CURRENT ROLES
Expert in Mechatronic Design and Robotics
Co-founder and co-director of the H-CoDe II Institute at Université Paris-Saclay
Supervisor of the Master's program M2 Mechatronics, Machine Vision, and Artificial Intelligence at Evry, Paris-Saclay University
Cofounder of Kalysta Company
Holder of an Industrial Excellence Chair in mechatronics at Evry, Paris-Saclay University
Deputy Director of IBISC Laboratory at Evry, Paris-Saclay University
ABOUT ME
My research aims to develop robust, powerful and safe robotic systems that improve mobility and independence.
I am a Full Professor of Mechatronic Systems at Université d'Évry – Paris-Saclay (UEPS), Université Paris-Saclay, and a member of the Informatique, BioInformatique et Systèmes Complexes - IBISC Laboratory, where I have served as Deputy Director since 2026. I also hold an Industrial Excellence Chair in exoskeletons and mechatronic design in partnership with SANDYC Industries. I am a co-founder and co-director of the Human-in-the-Loop Control and Decision Institute (H-CoDe II) at Université Paris-Saclay.
From 2011 to 2019, I was an Associate Professor in Humanoid Robotics at Versailles Saint-Quentin-en-Yvelines University, UVSQ, where I held an Industrial Excellence Chair in hydraulic domestication in partnership with BIA.
I obtained my HDR (Habilitation à Diriger des Recherches) in Mechatronics from UVSQ in 2017.
Before that, I was a Postdoctoral Research Fellow at the Technical University of Munich, Germany, supported by the Alexander von Humboldt Foundation. I received my Ph.D. in Robotics from UVSQ in 2009, for which I received the Best Ph.D. Thesis Award in Robotics from the French CNRS and the Best Ph.D. Thesis Award in Mechatronics for the 20th Anniversary of UVSQ.
My research covers mechatronic design, humanoid robotics, assistive devices, exoskeletons, and electro-hydraulic actuation. I have served as Principal Investigator or scientific leader on several French national and industrial research projects.
I co-coordinate the Institute for Control and Decision (iCode Paris-Saclay) and the H-CoDe Paris-Saclay. To date, my work includes 53 international patent publications, more than €5.5 million in research funding, over 16 projects managed, and 19 Ph.D. theses supervised.
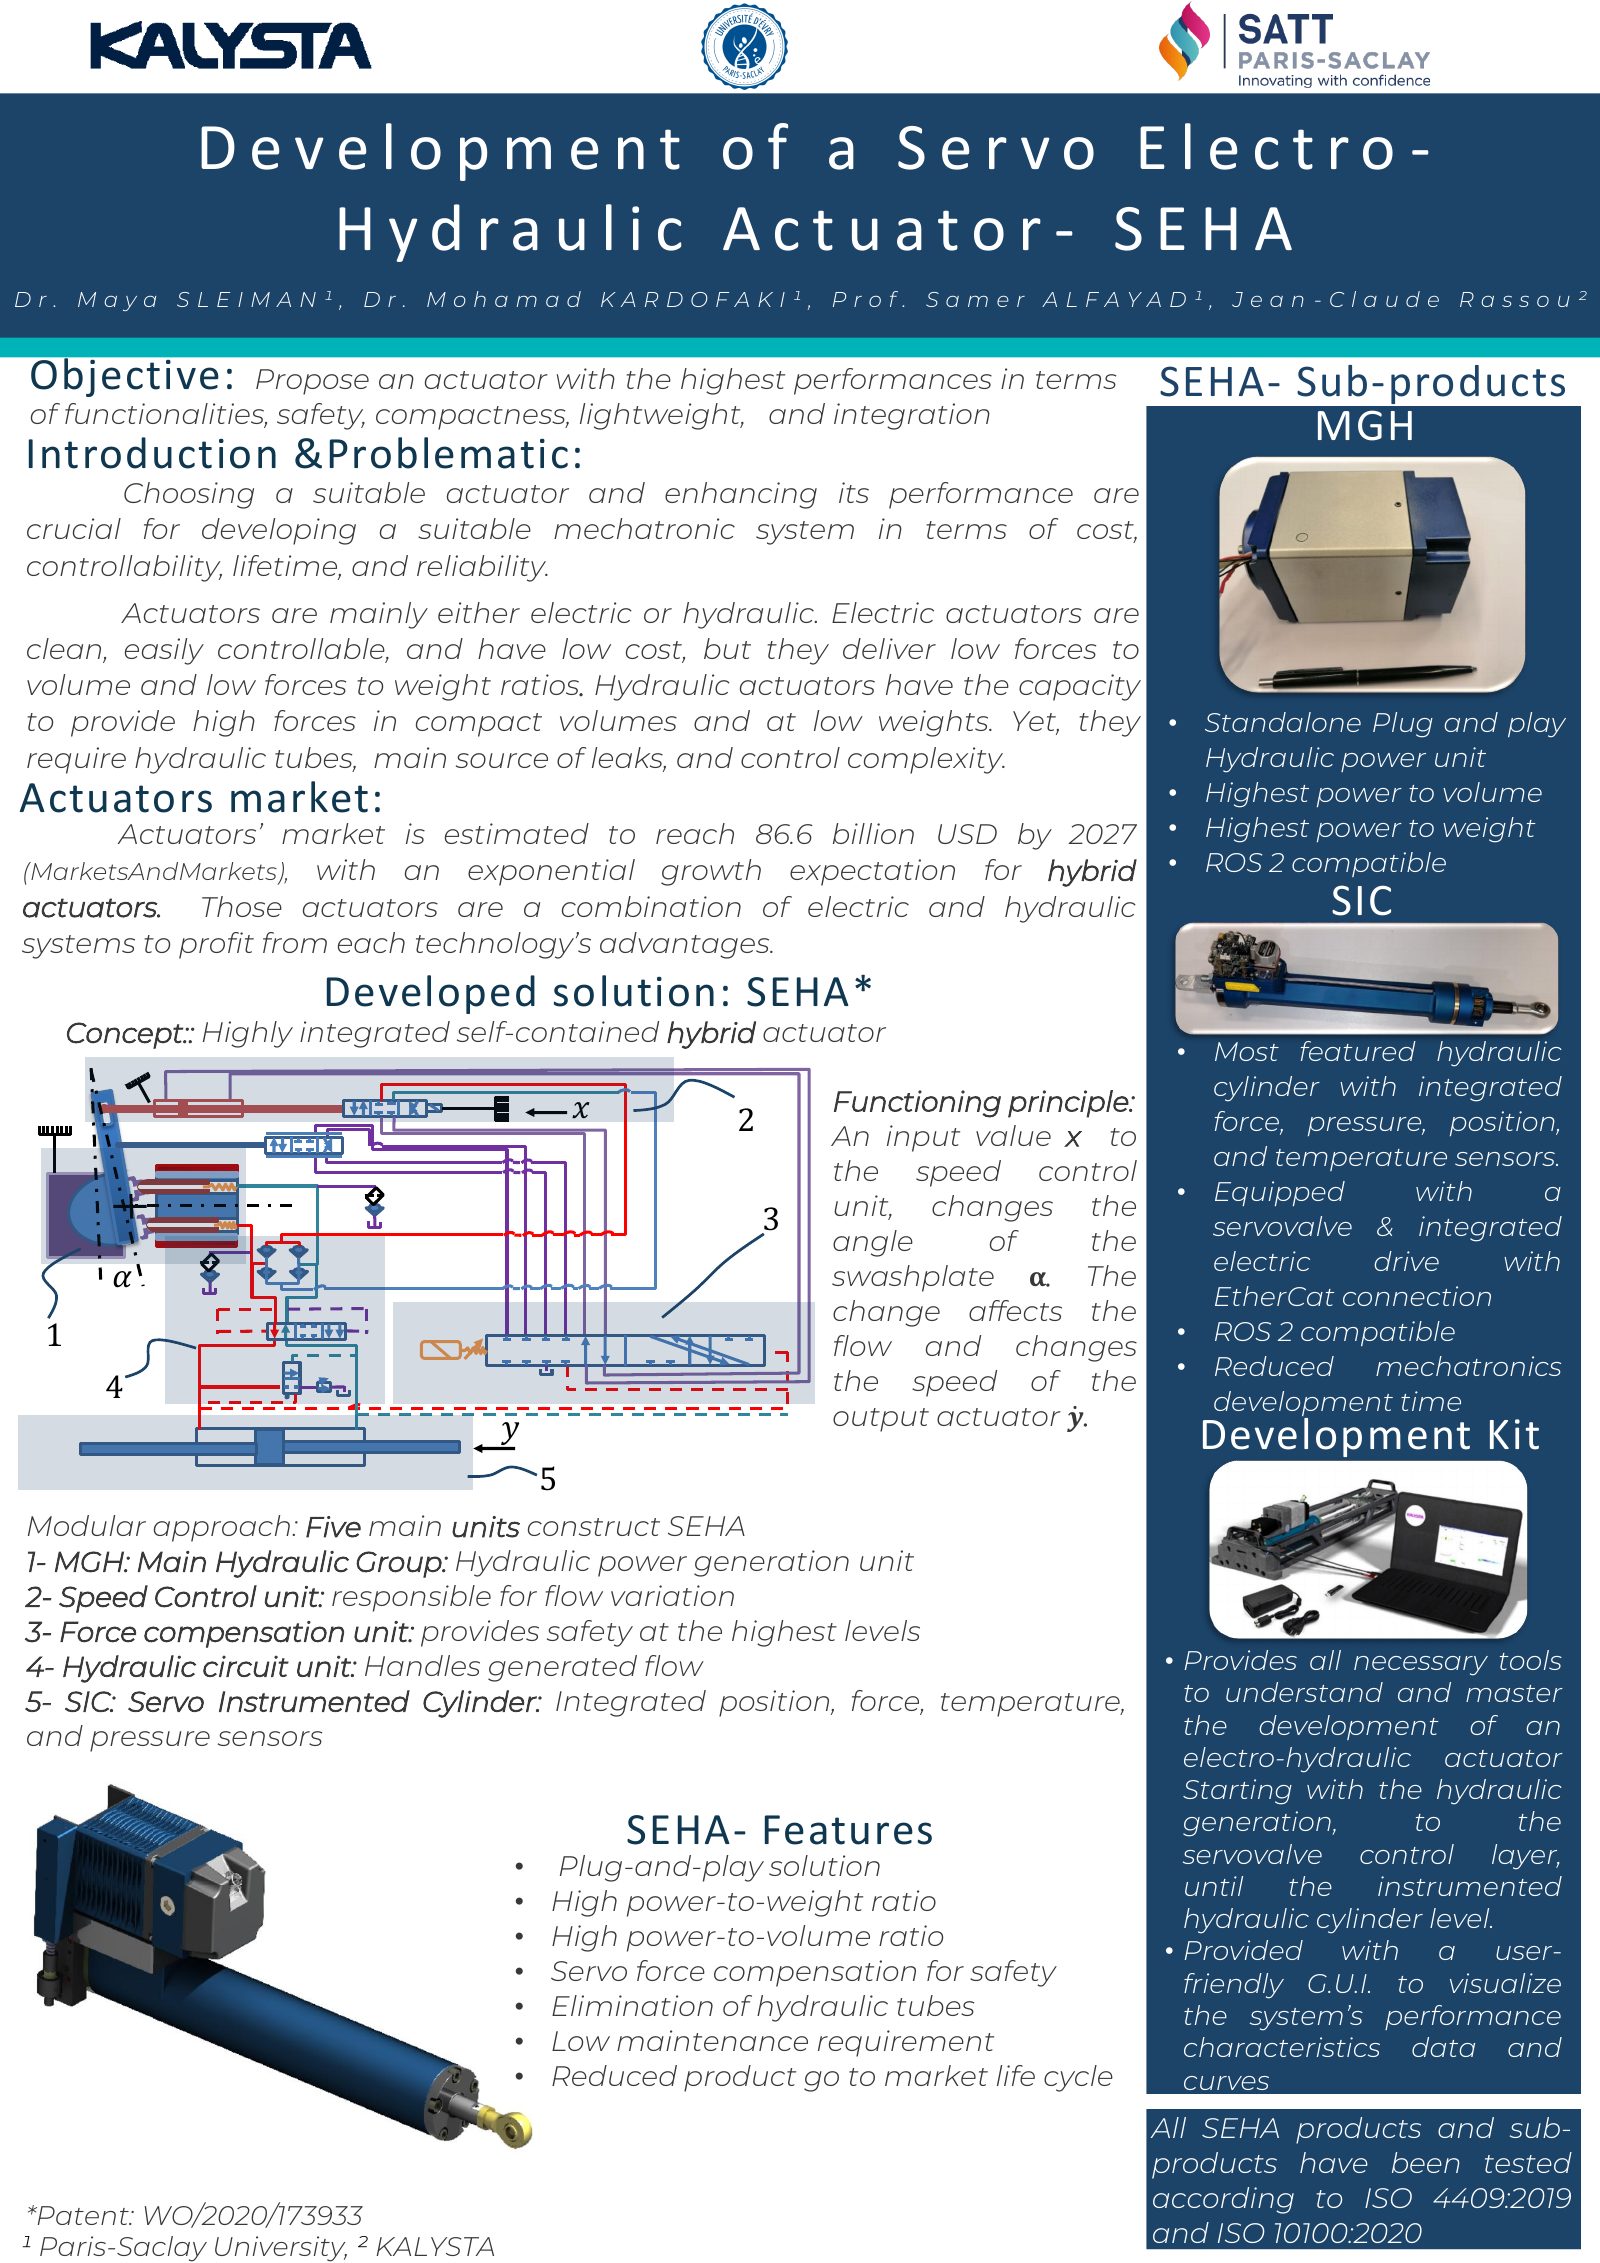
I also co-founded KALYSTA, a mechatronics startup established in 2020 to transfer research innovations into industrial applications. KALYSTA emerged from the SEHA project funded by SATT Paris Saclay in close collaboration with UEPS and UVSQ, which focused on advanced servo electro-hydraulic actuation. The company aims to bring innovative mechatronic systems developed through academic research to market. KALYSTA strengthens the link between research, technological development, and industry.
AT A GLANCE
RESEARCH
From integrated mechanisms to complete robotic systems, the research connects design, control and human interaction.
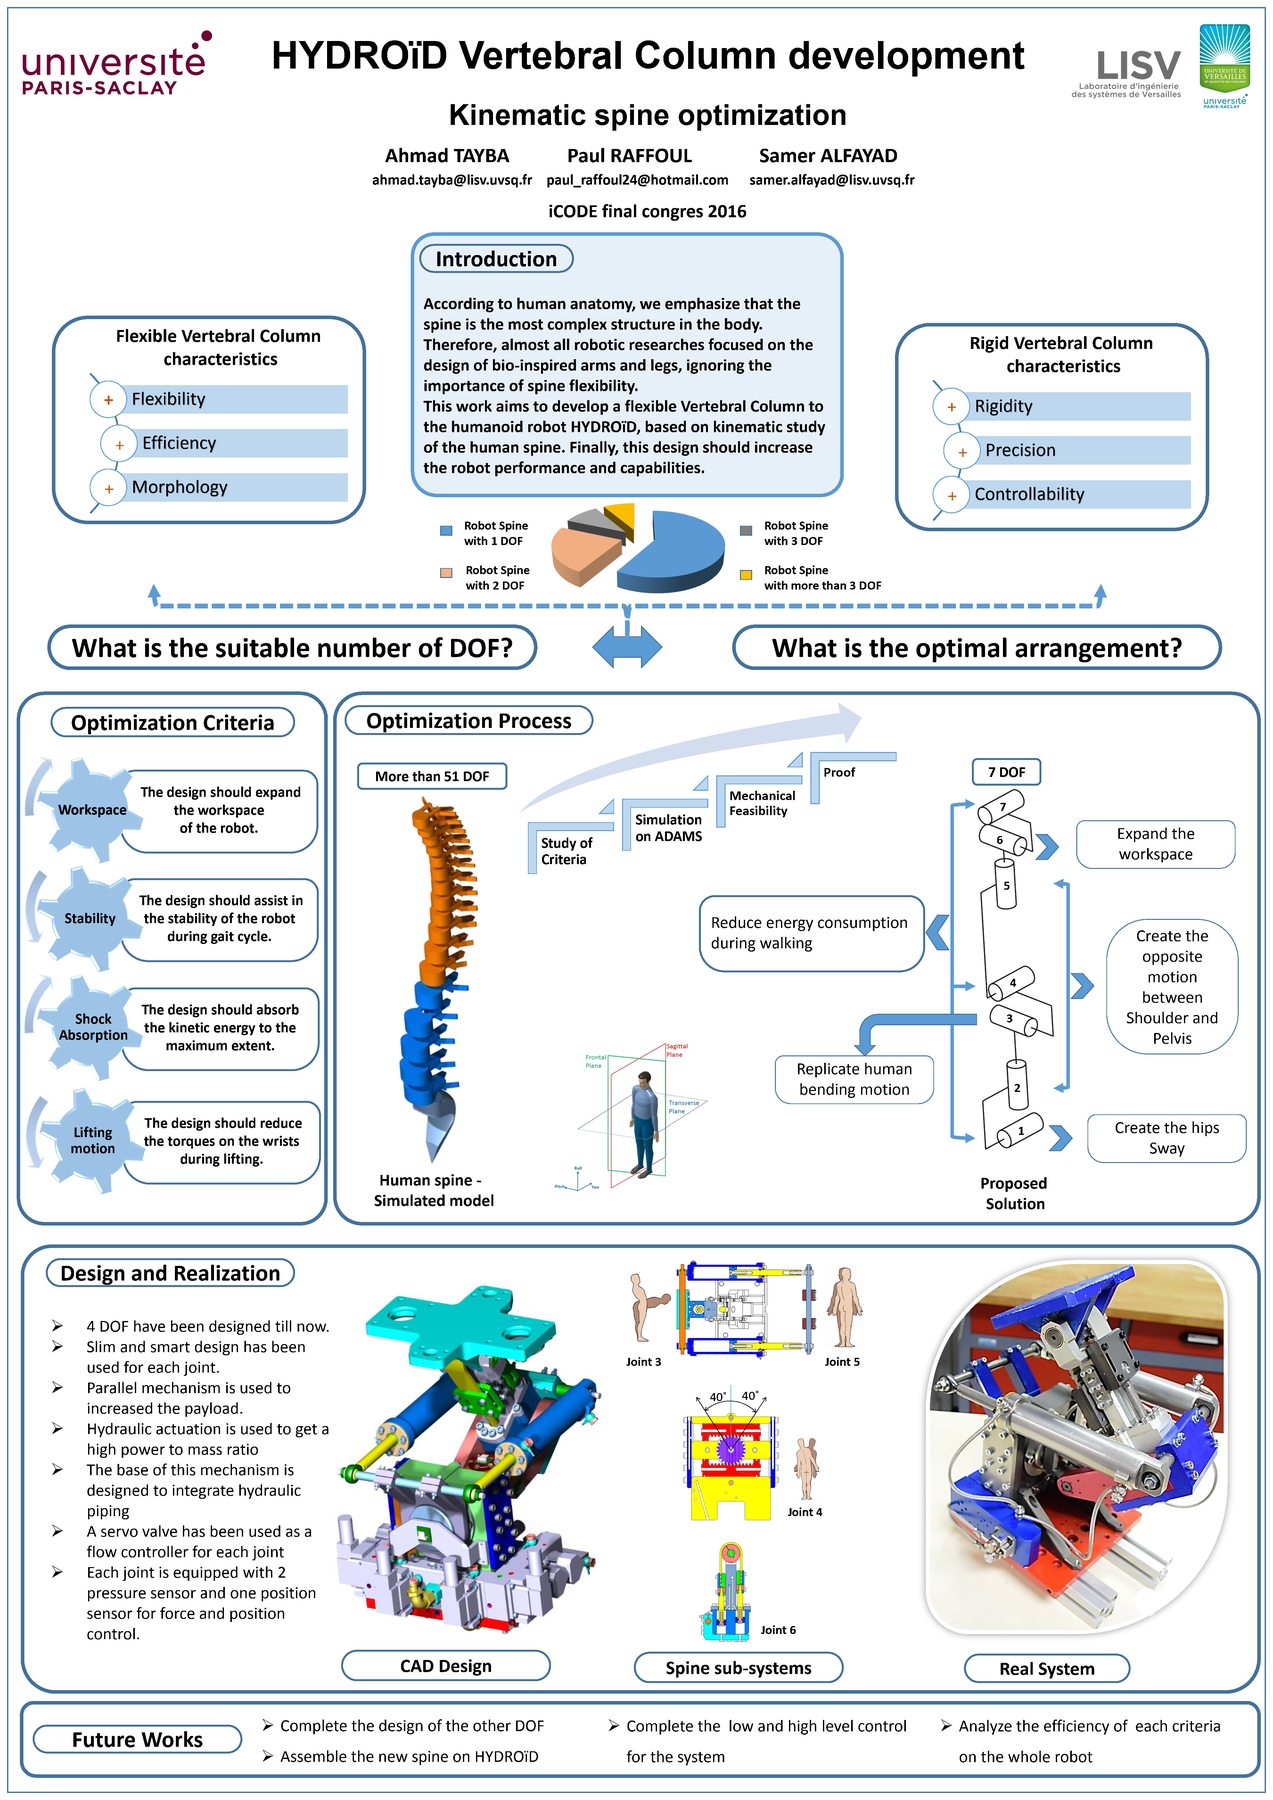
Human-inspired mechanisms, integrated actuation and control architectures for capable, coordinated movement.
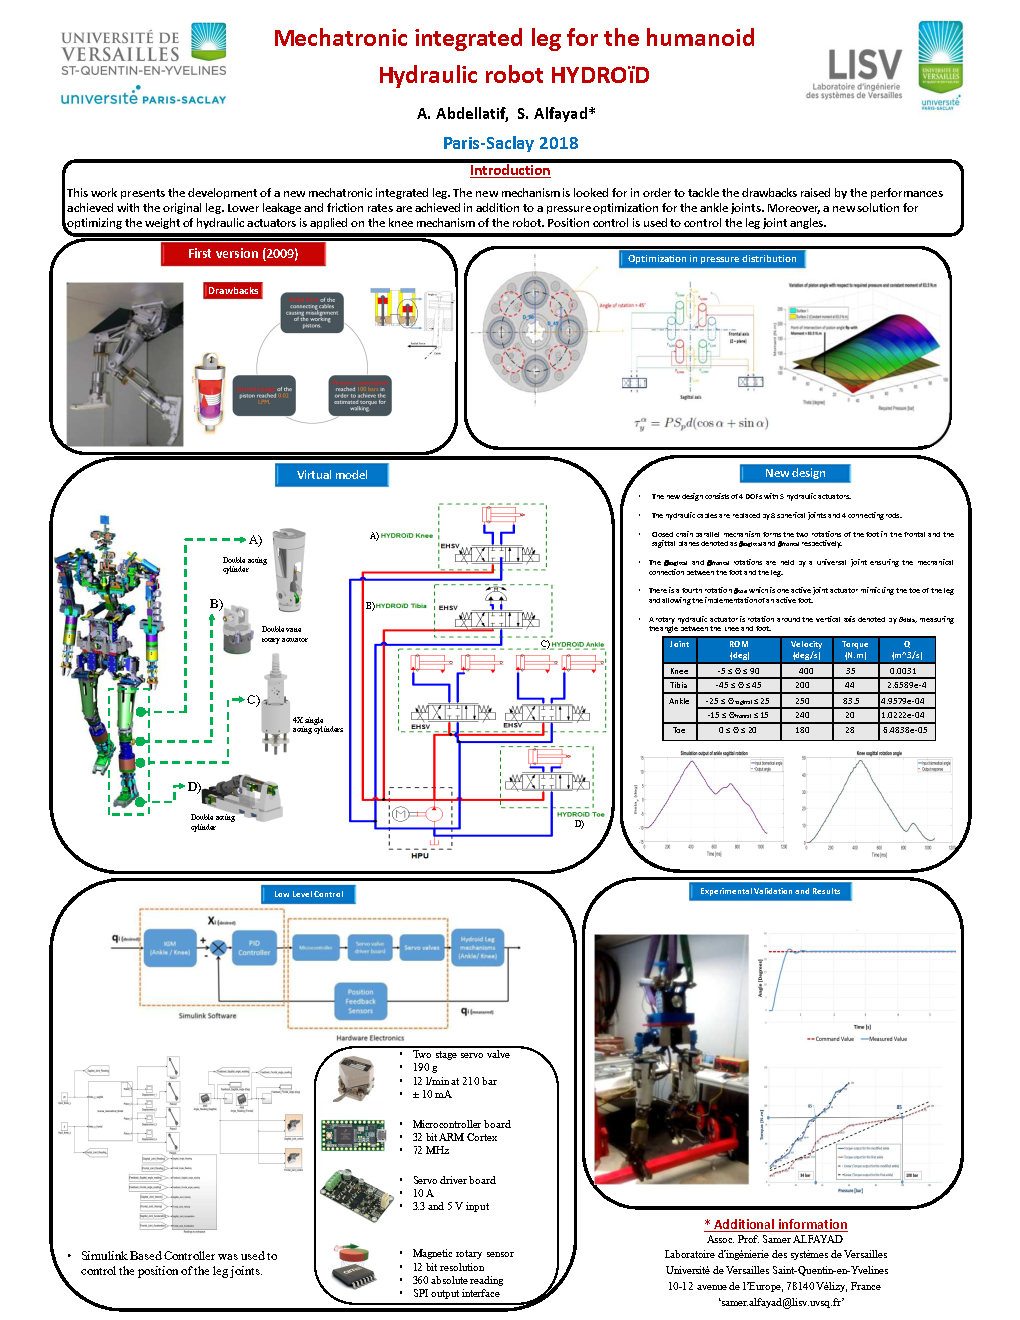
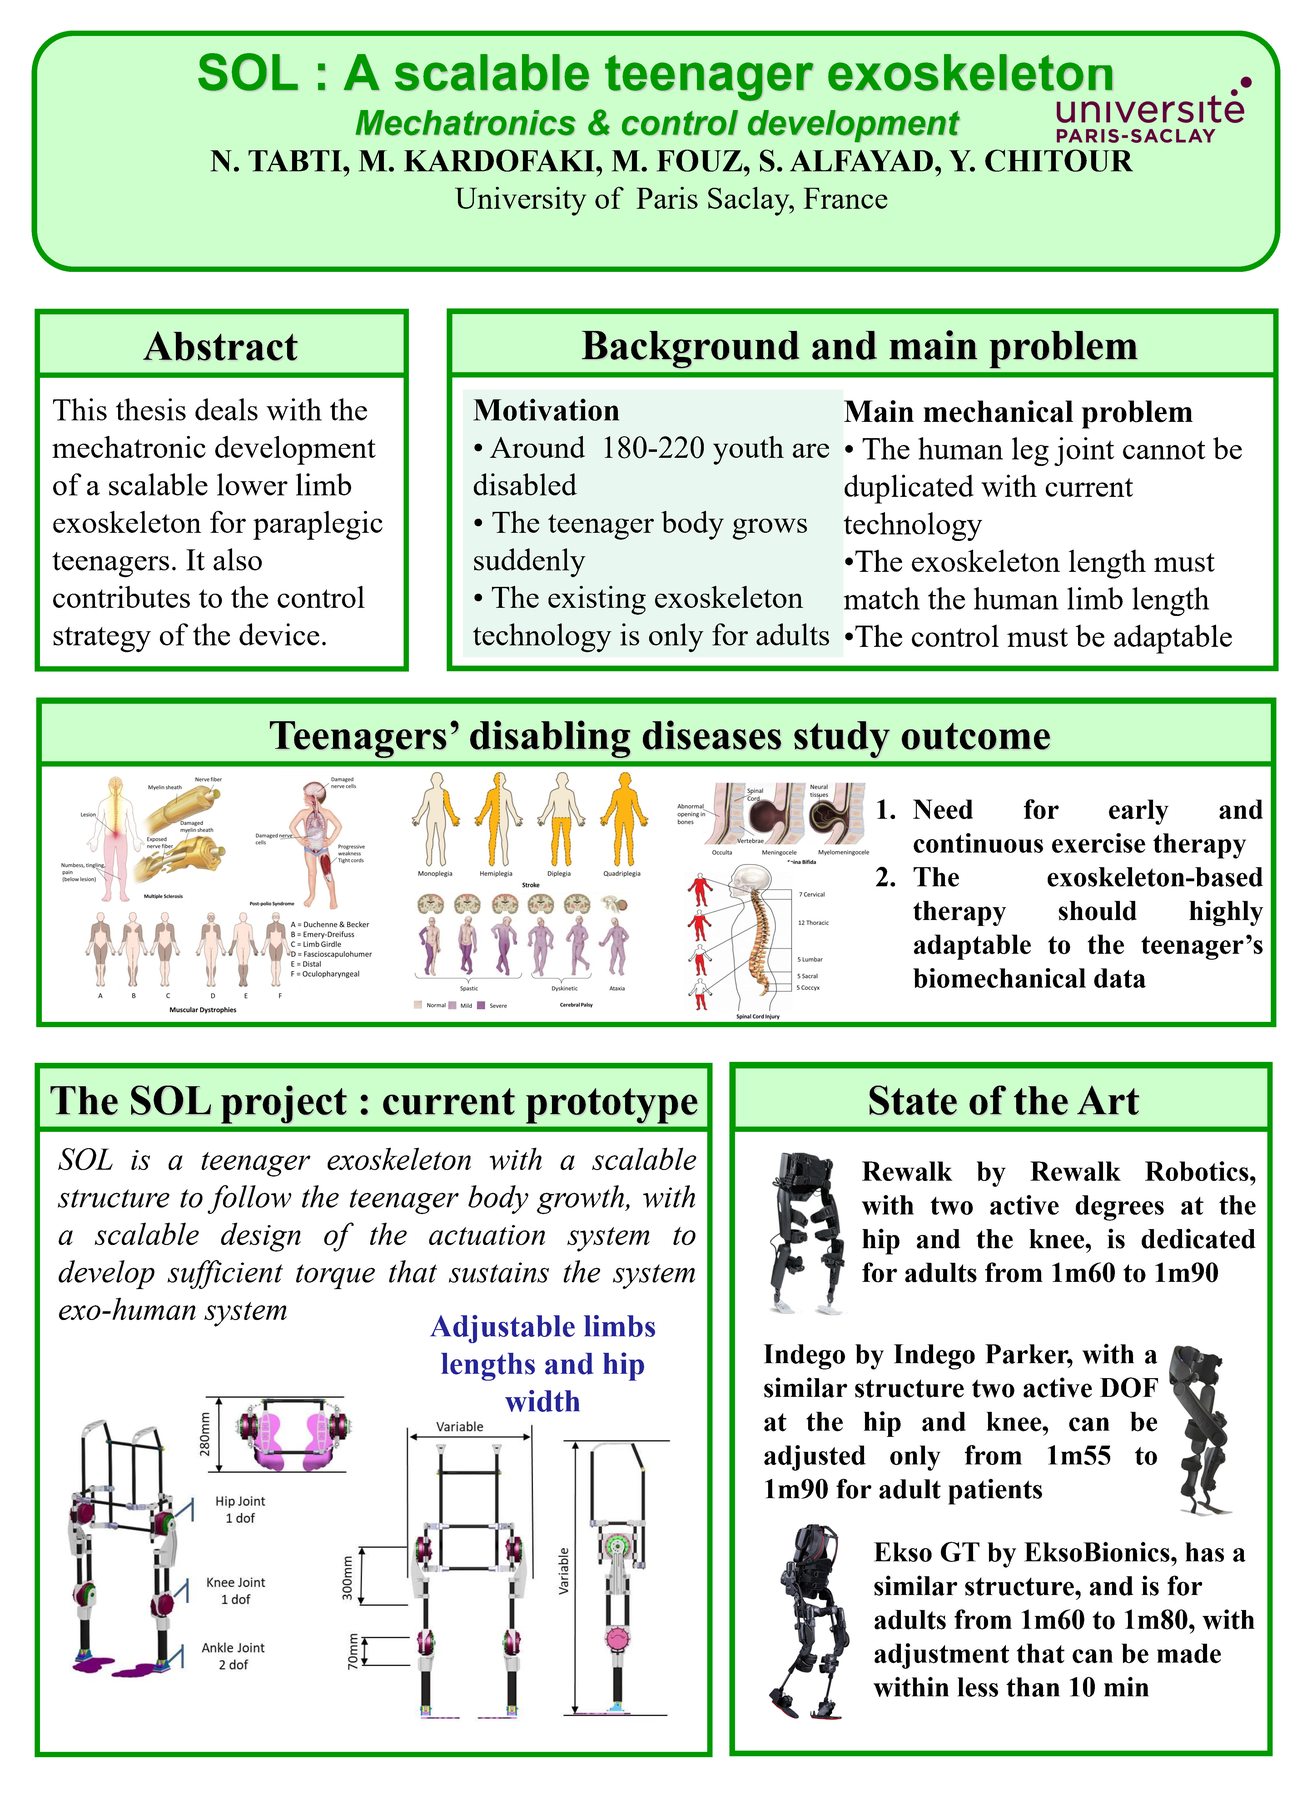
HYDROïD · ROMEO2Wearable exoskeletons and mobility assistance designed around the needs, safety and autonomy of people.
SANDYC CHAIR · EXO-SOLCompact electro-hydraulic systems and embedded control to bring high performance into practical robotic applications.
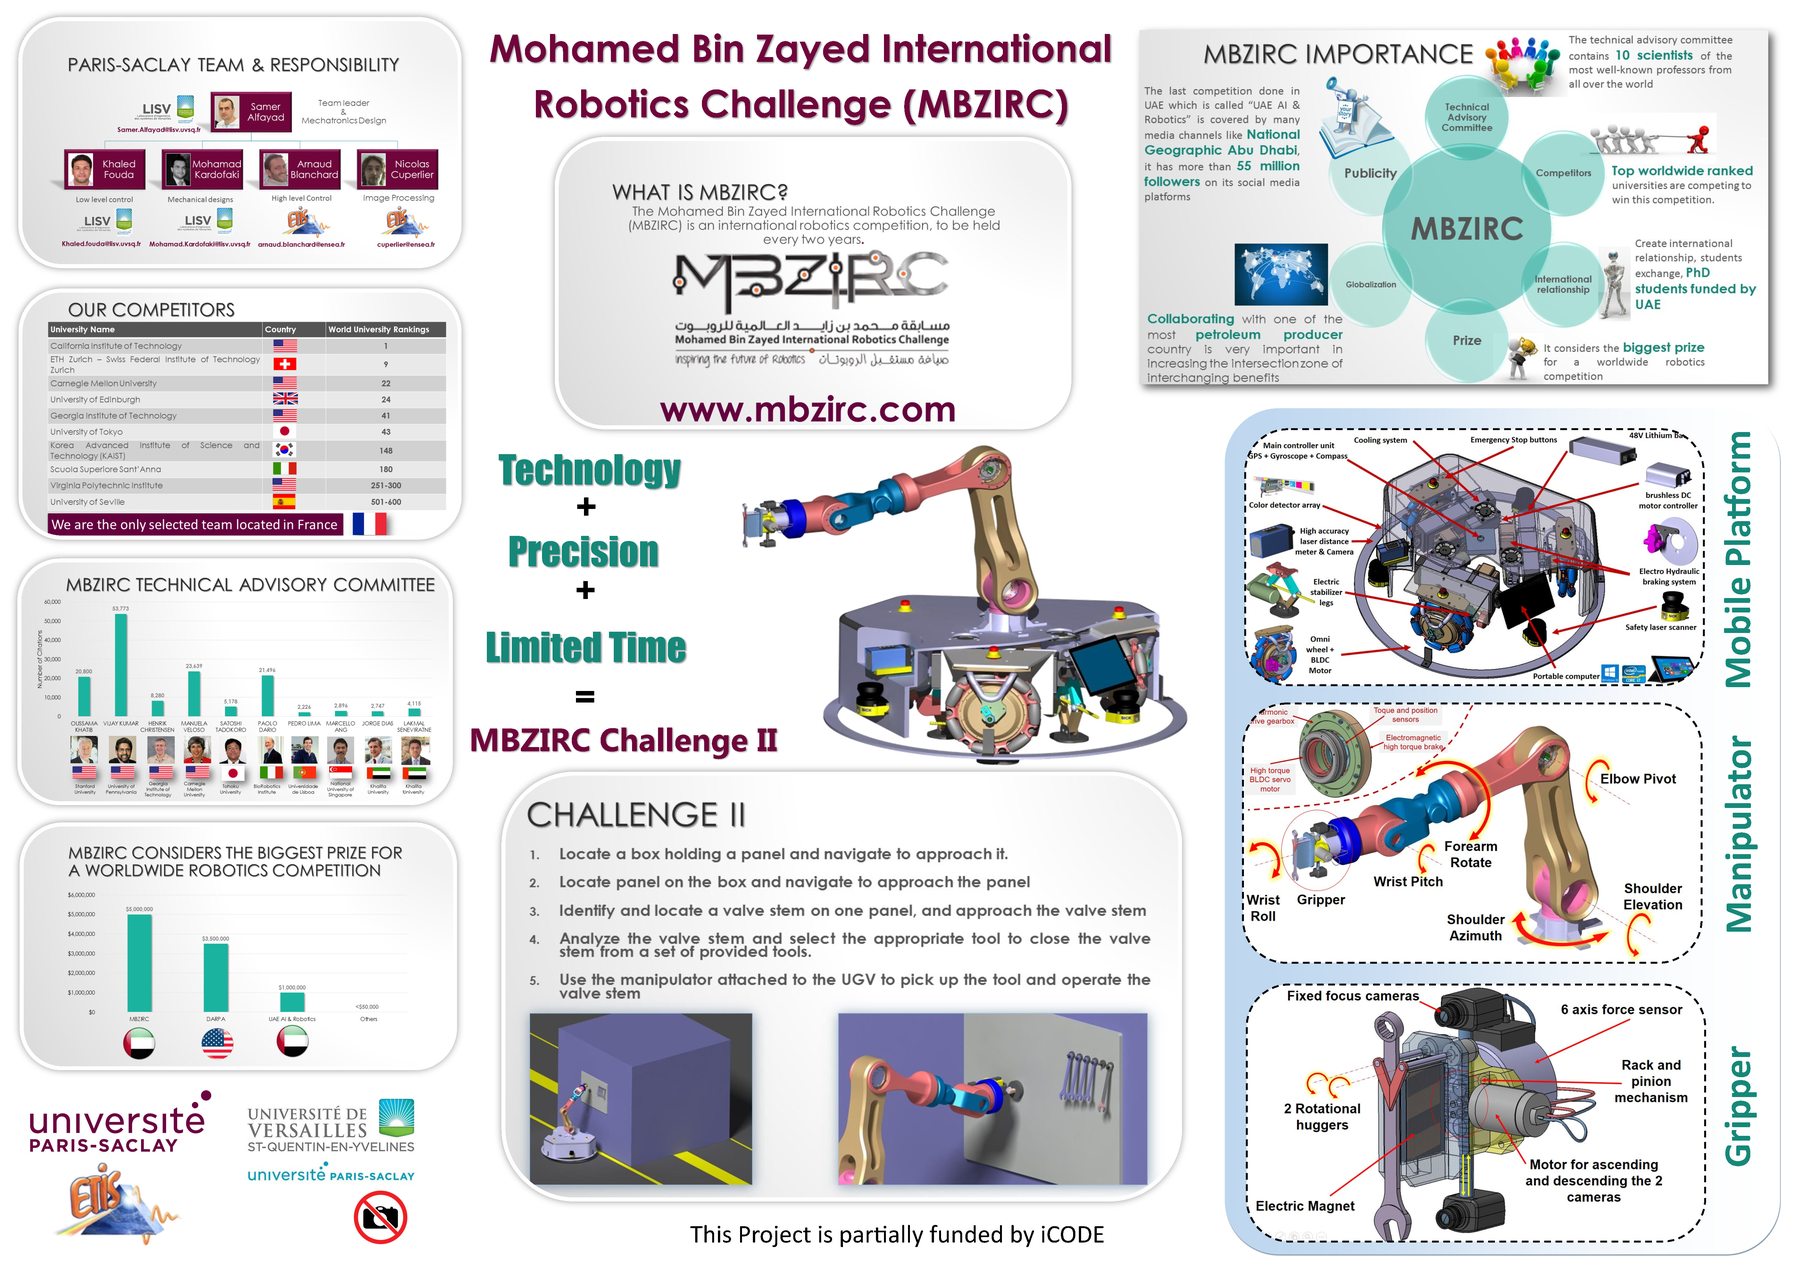
SEHA · KALYSTAOmnidirectional mobile platforms combining mechanical design and embedded control for coordinated movement in complex environments.
MBZIRC 2017Design and control of multi-joint robotic arms integrated with mobile platforms for precise manipulation.
MBZIRC 2017 · 6-DOF MANIPULATORRESEARCH LEADERSHIP
Project leadership across humanoid robotics, assistive systems and mechatronics.
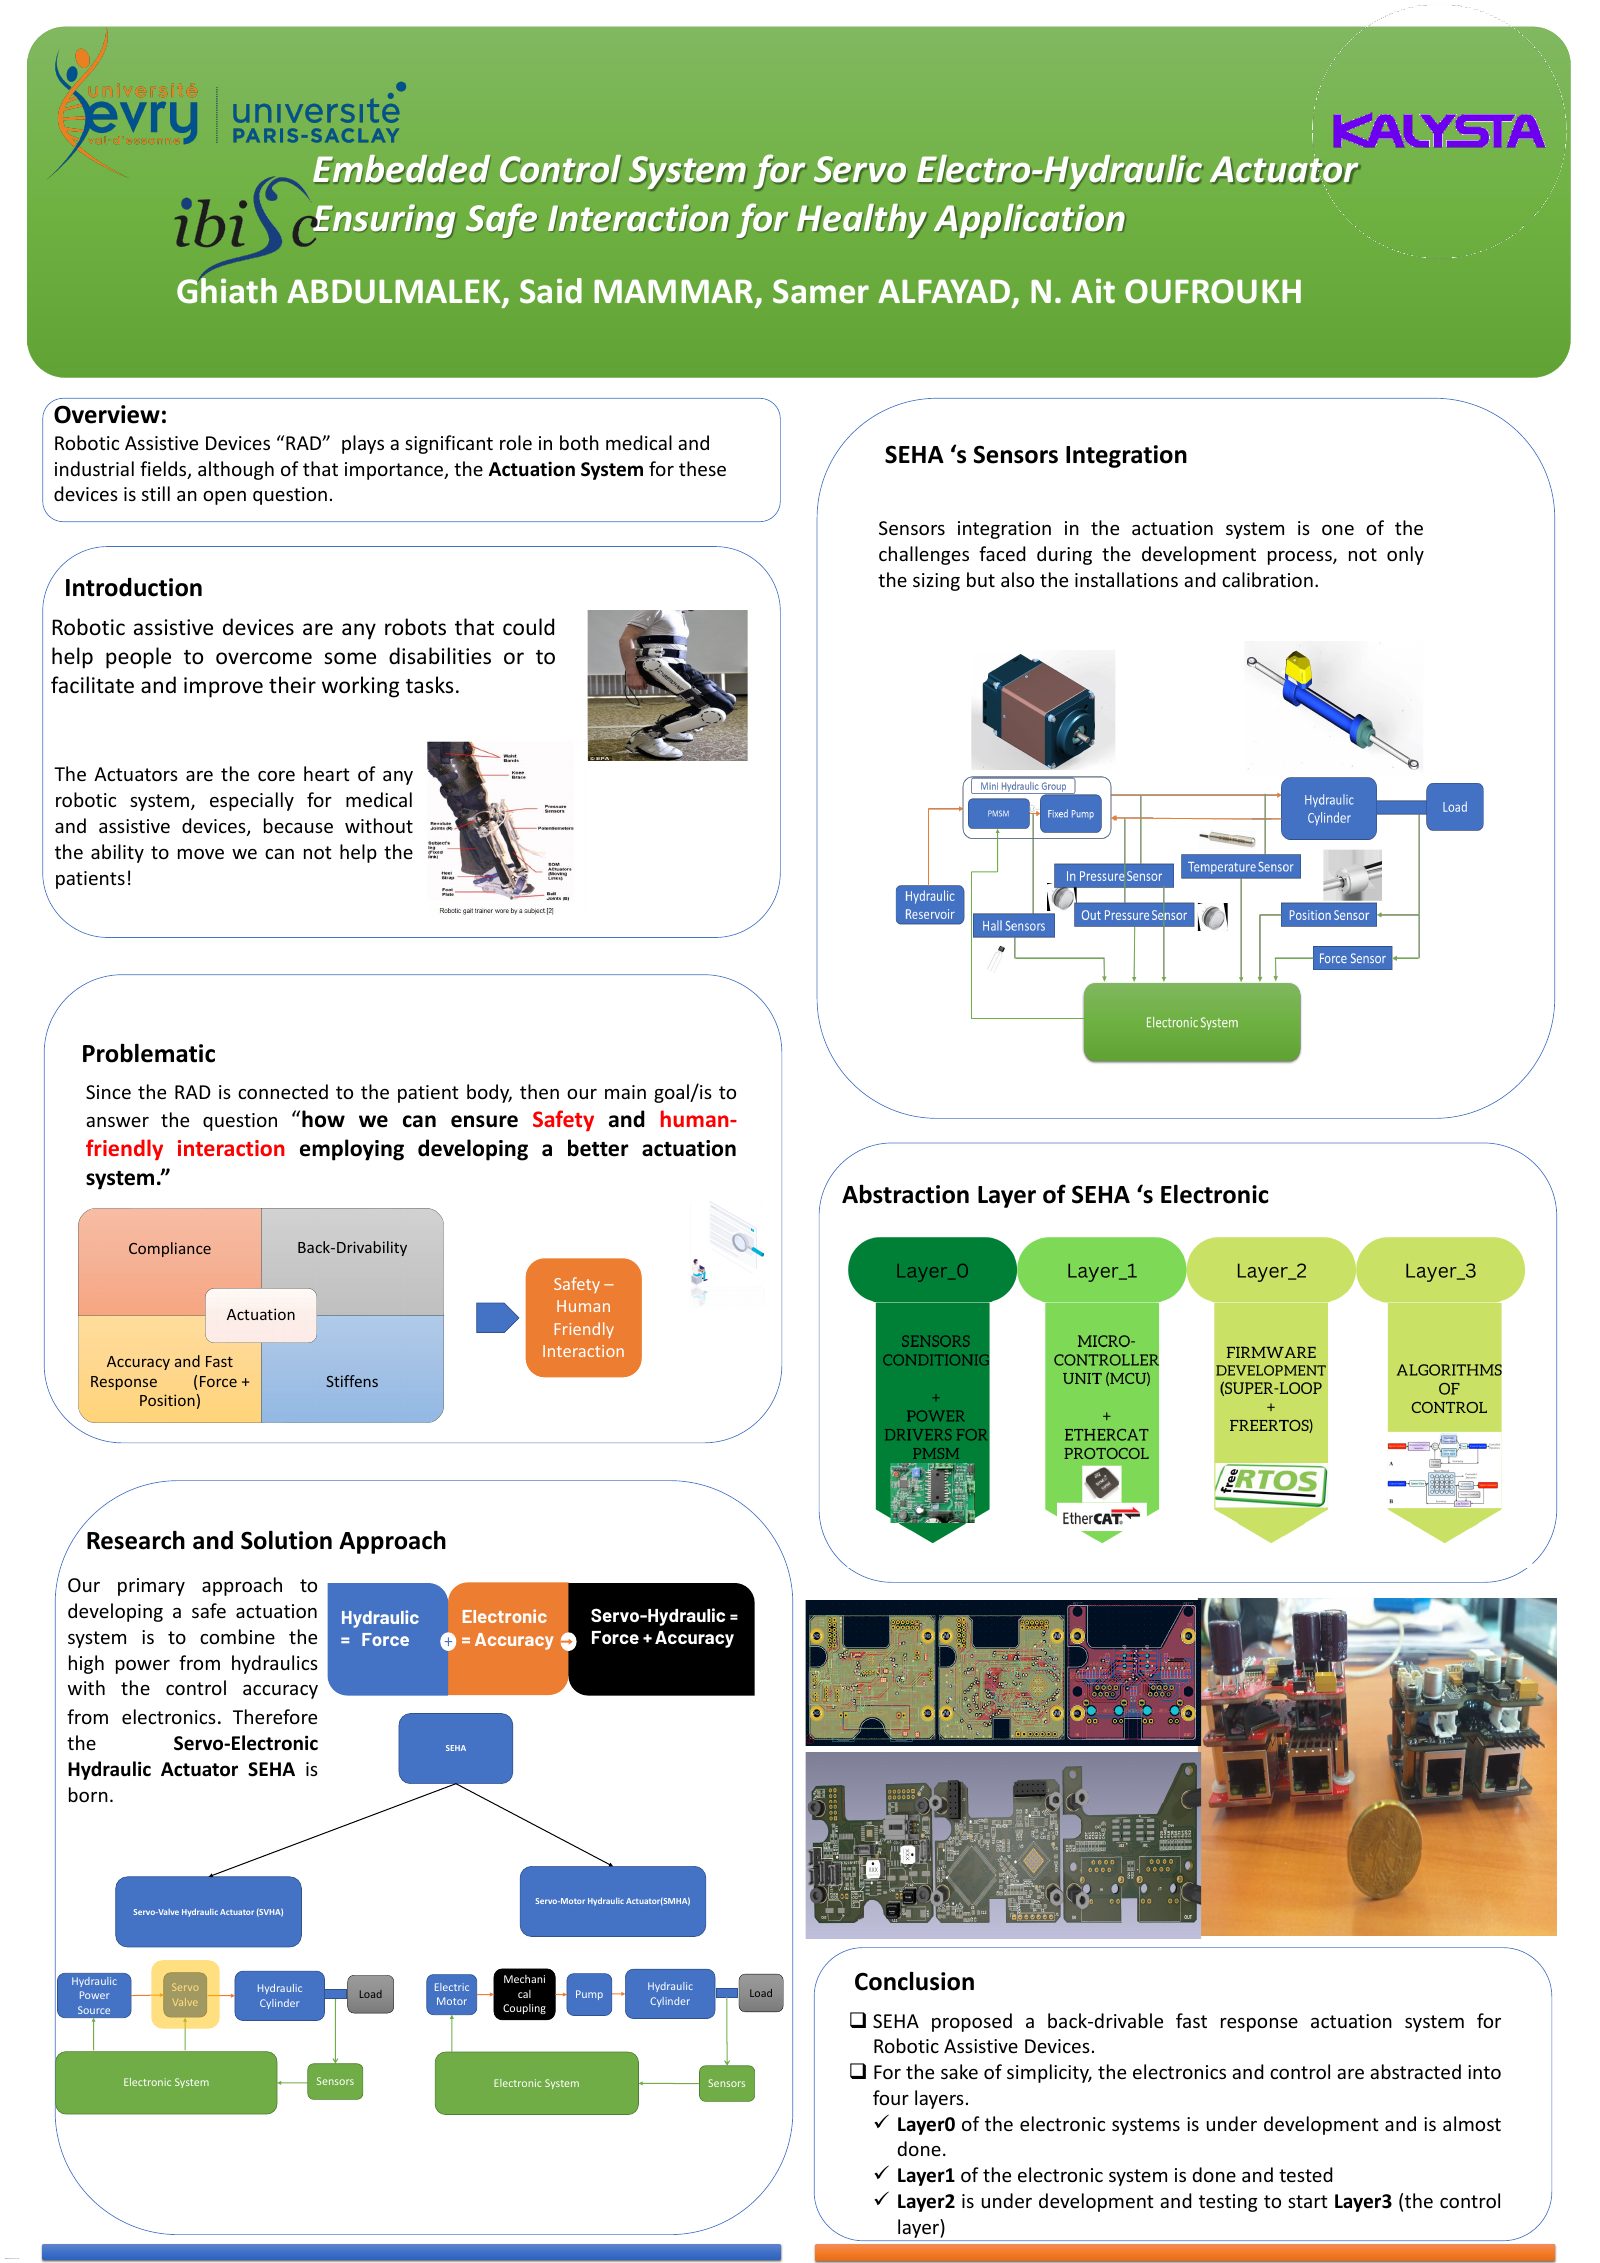
Funded by SATT Paris-Saclay. The project aims to validate an innovative, ROS 2-compatible electro-hydraulic actuator combining hydraulic performance with the simplicity, cost, size, and weight advantages of electric actuators. It includes a patented force-compensation solution. The startup KALYSTA was created in 2020 to market the products developed within this project.
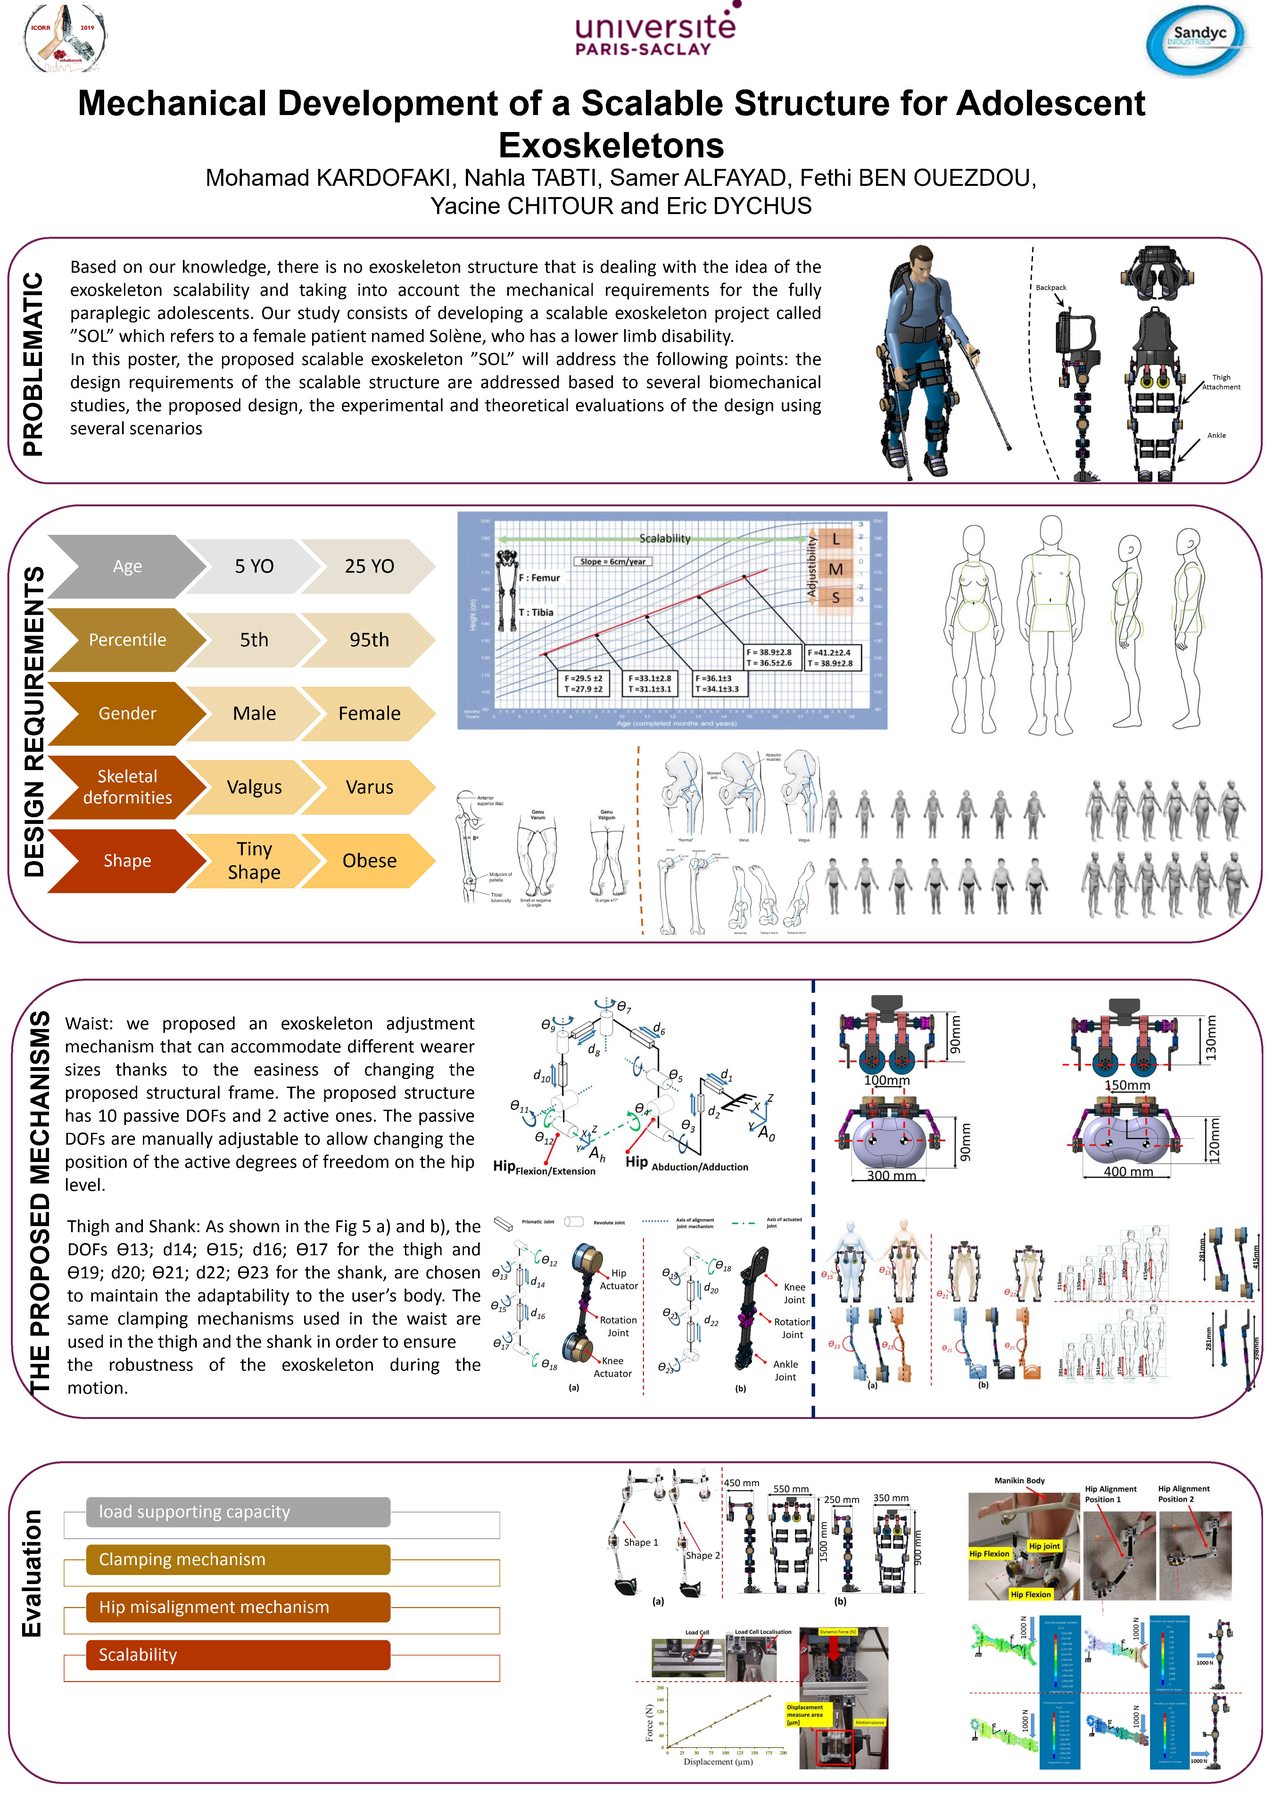
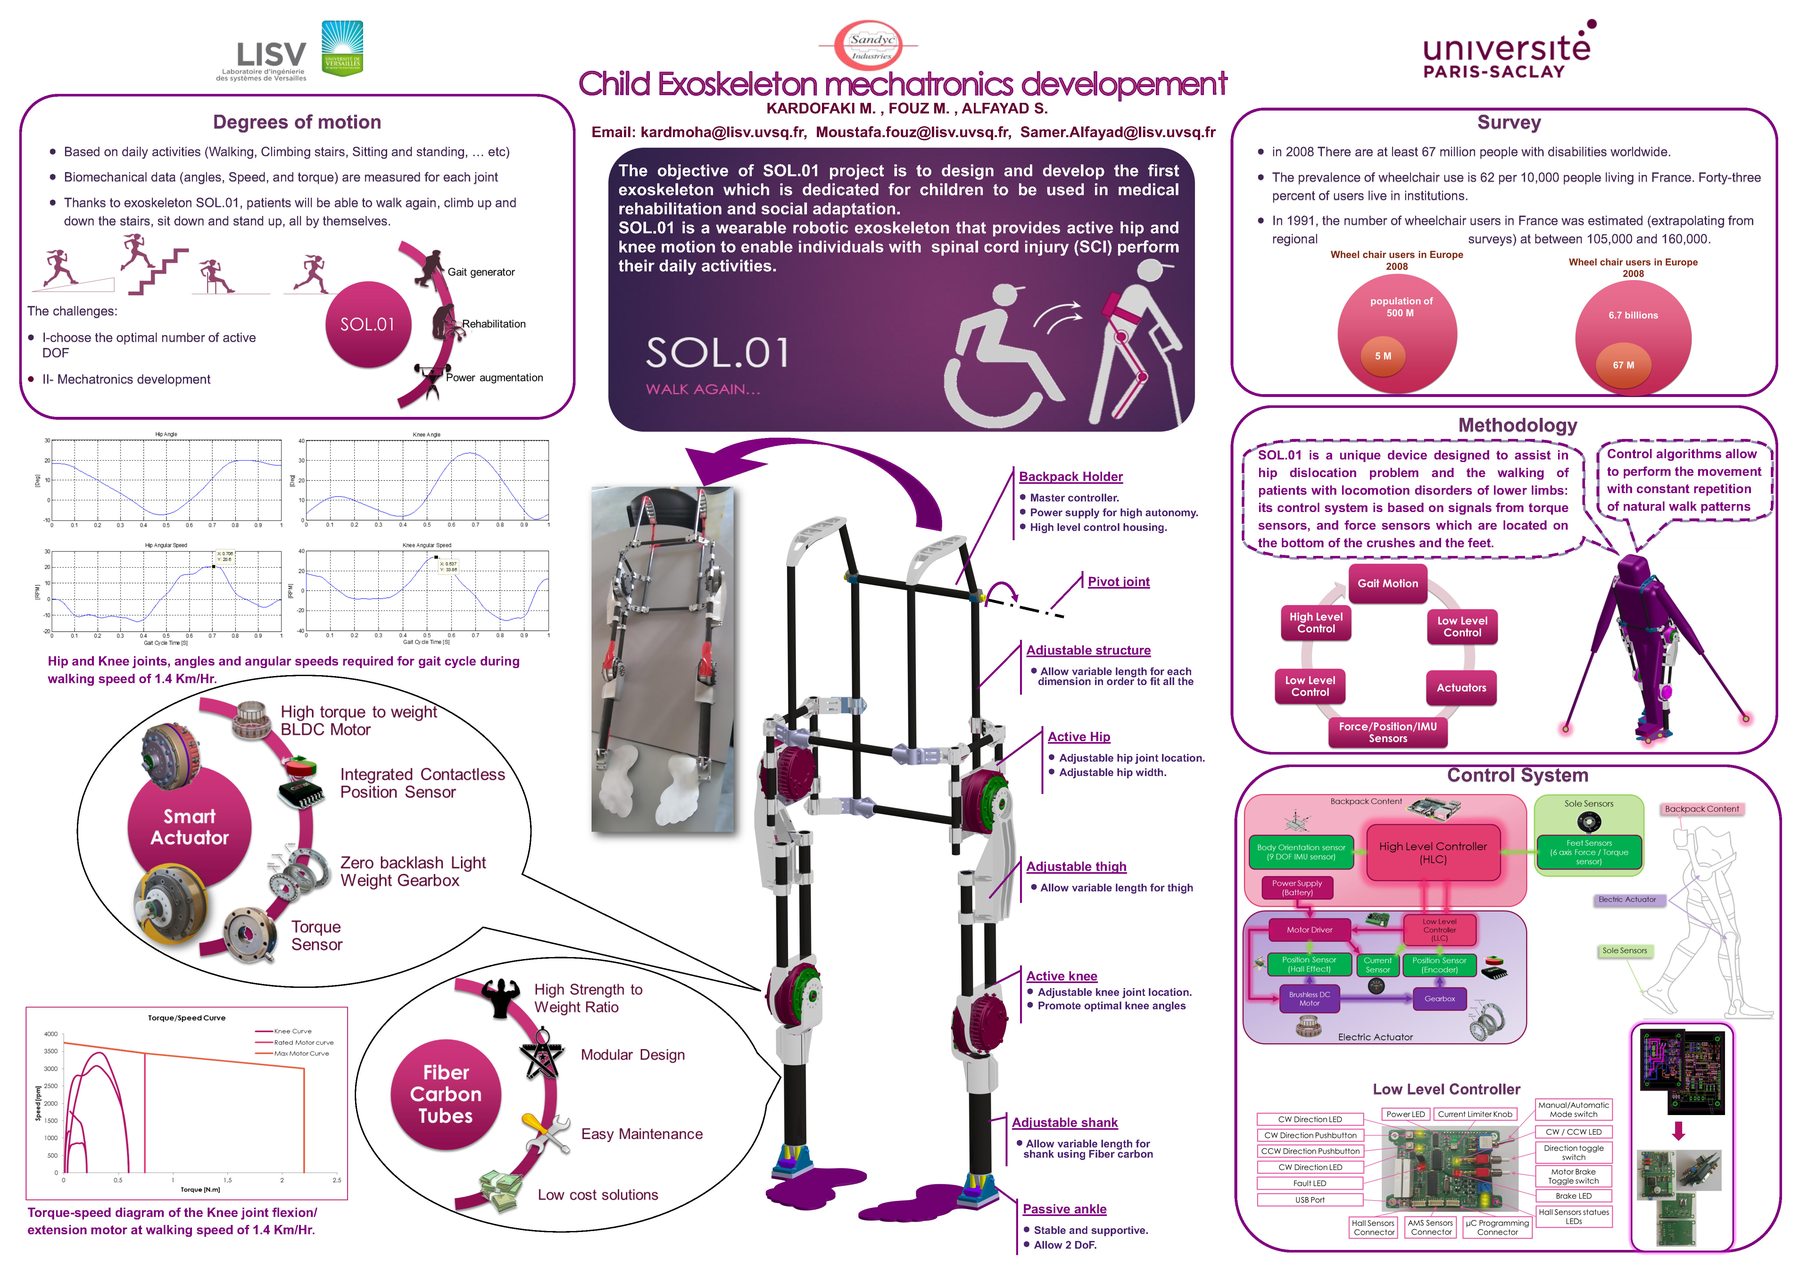
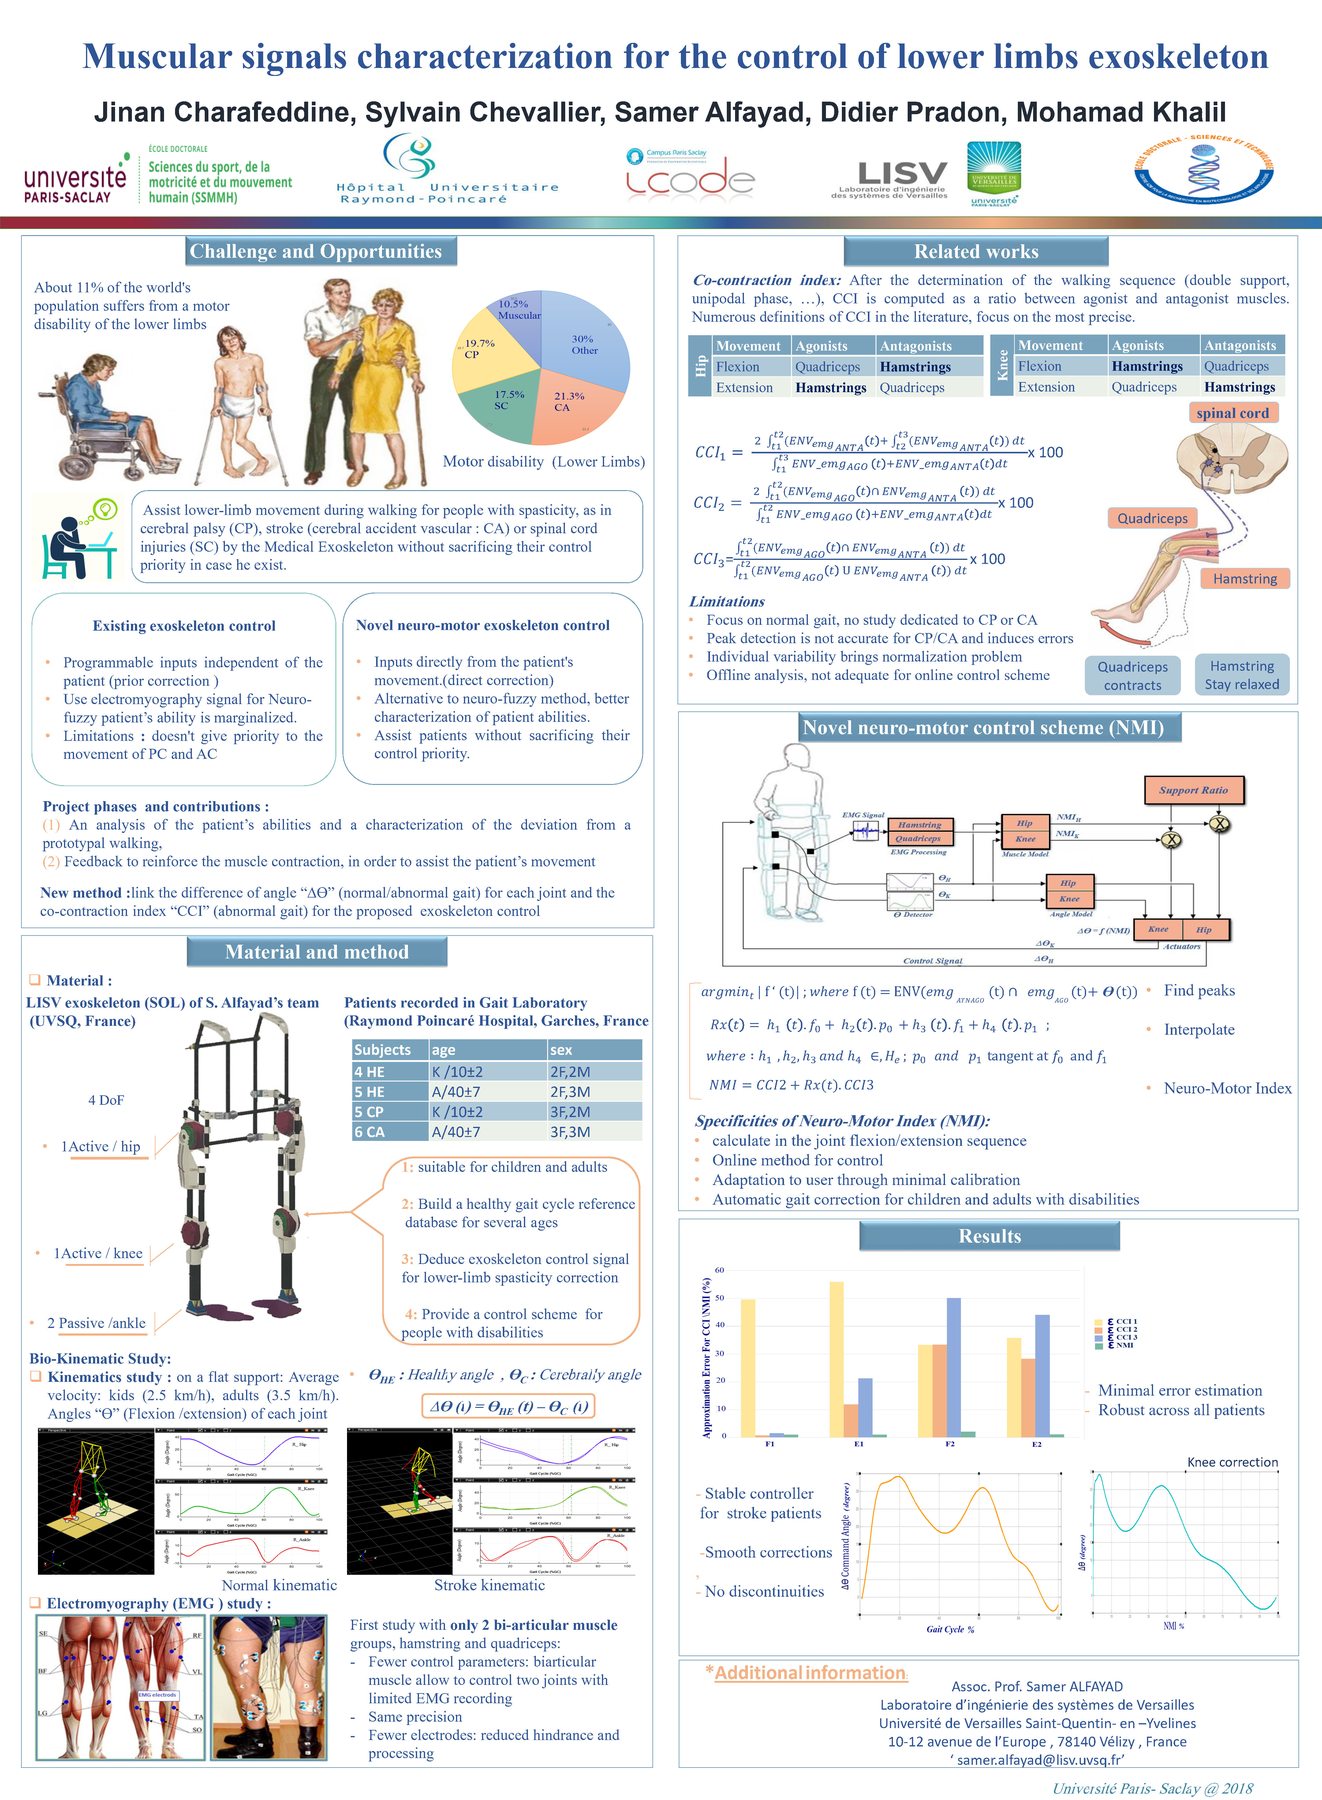
"Evolutive Exoskeleton for Adolescents with Reduced Mobility", funded by MESR, UEPS and ANR.
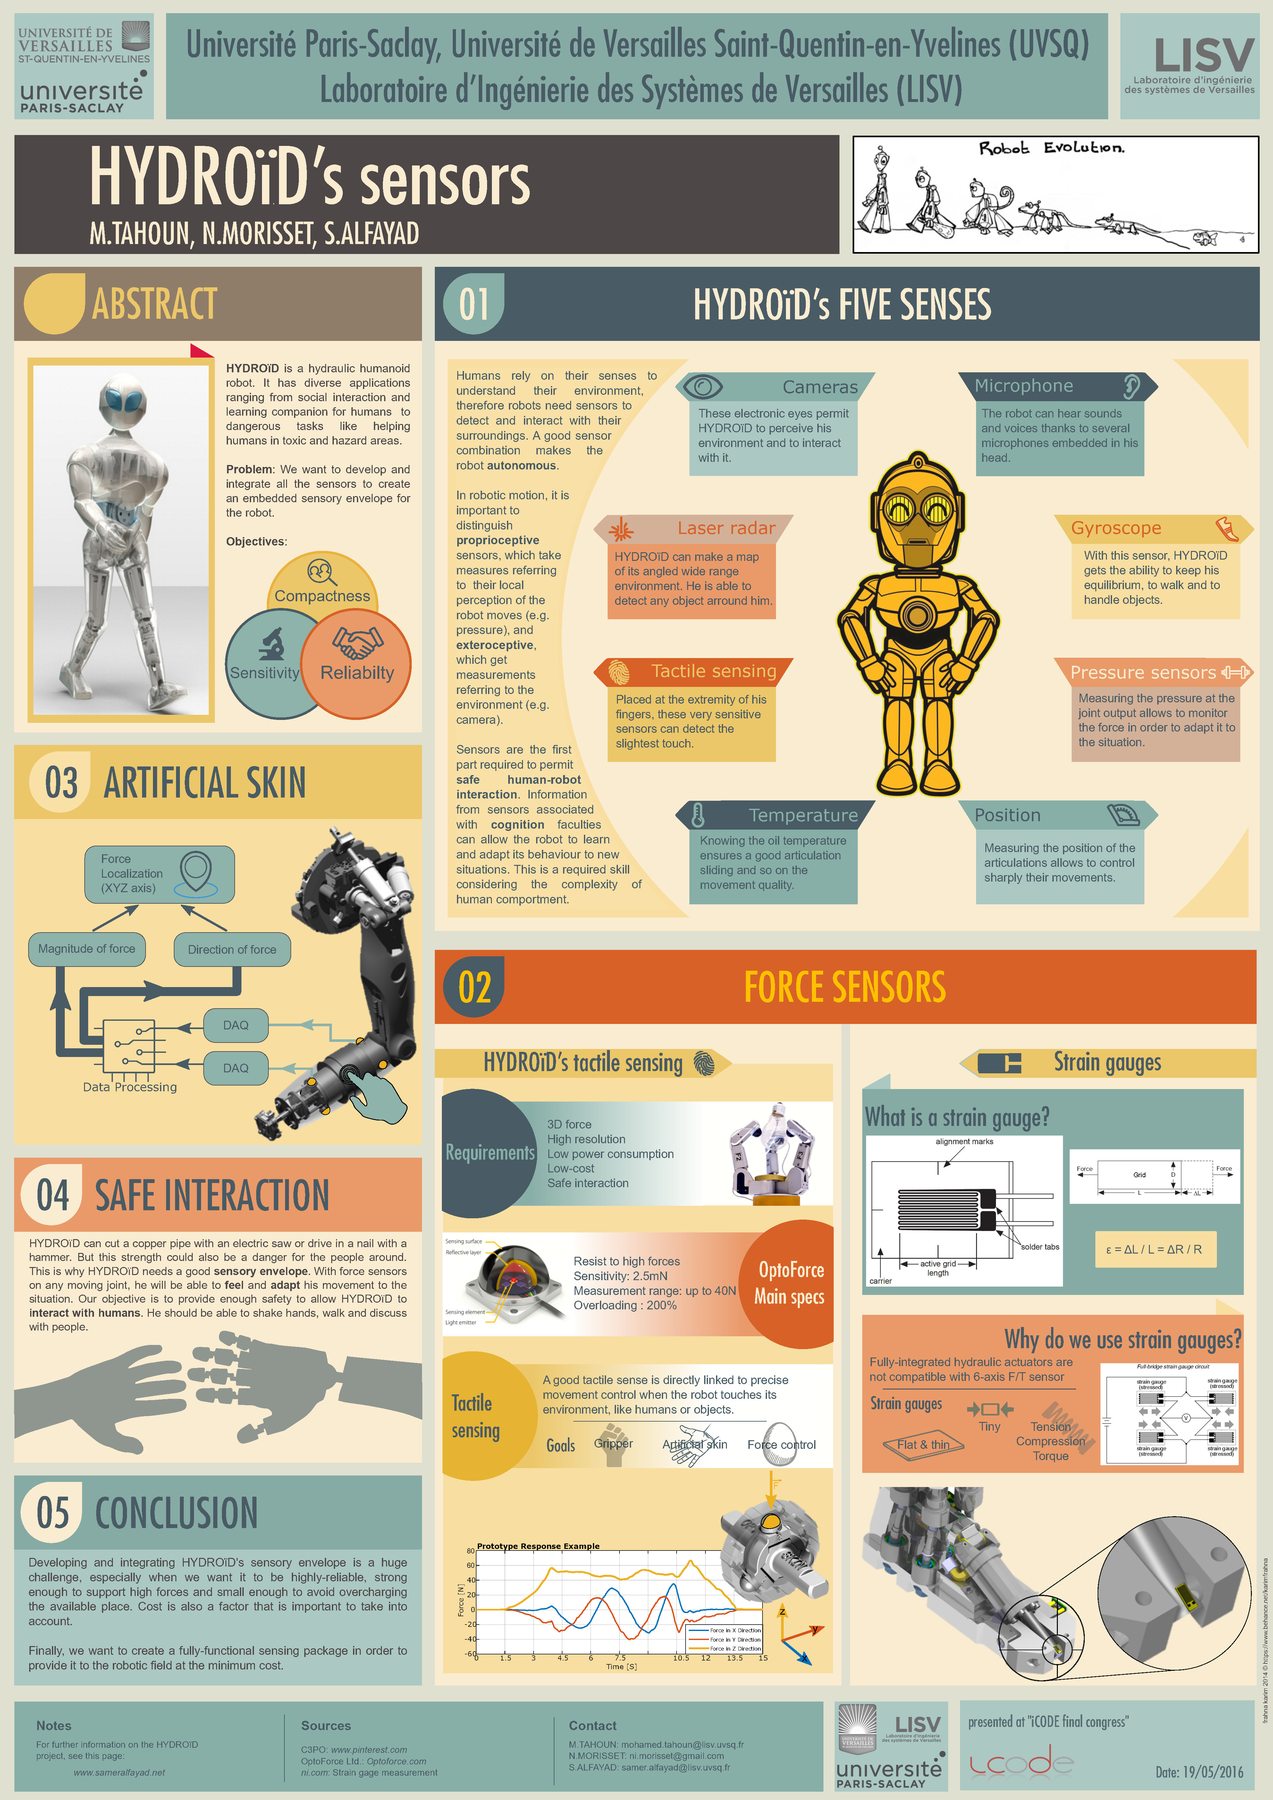
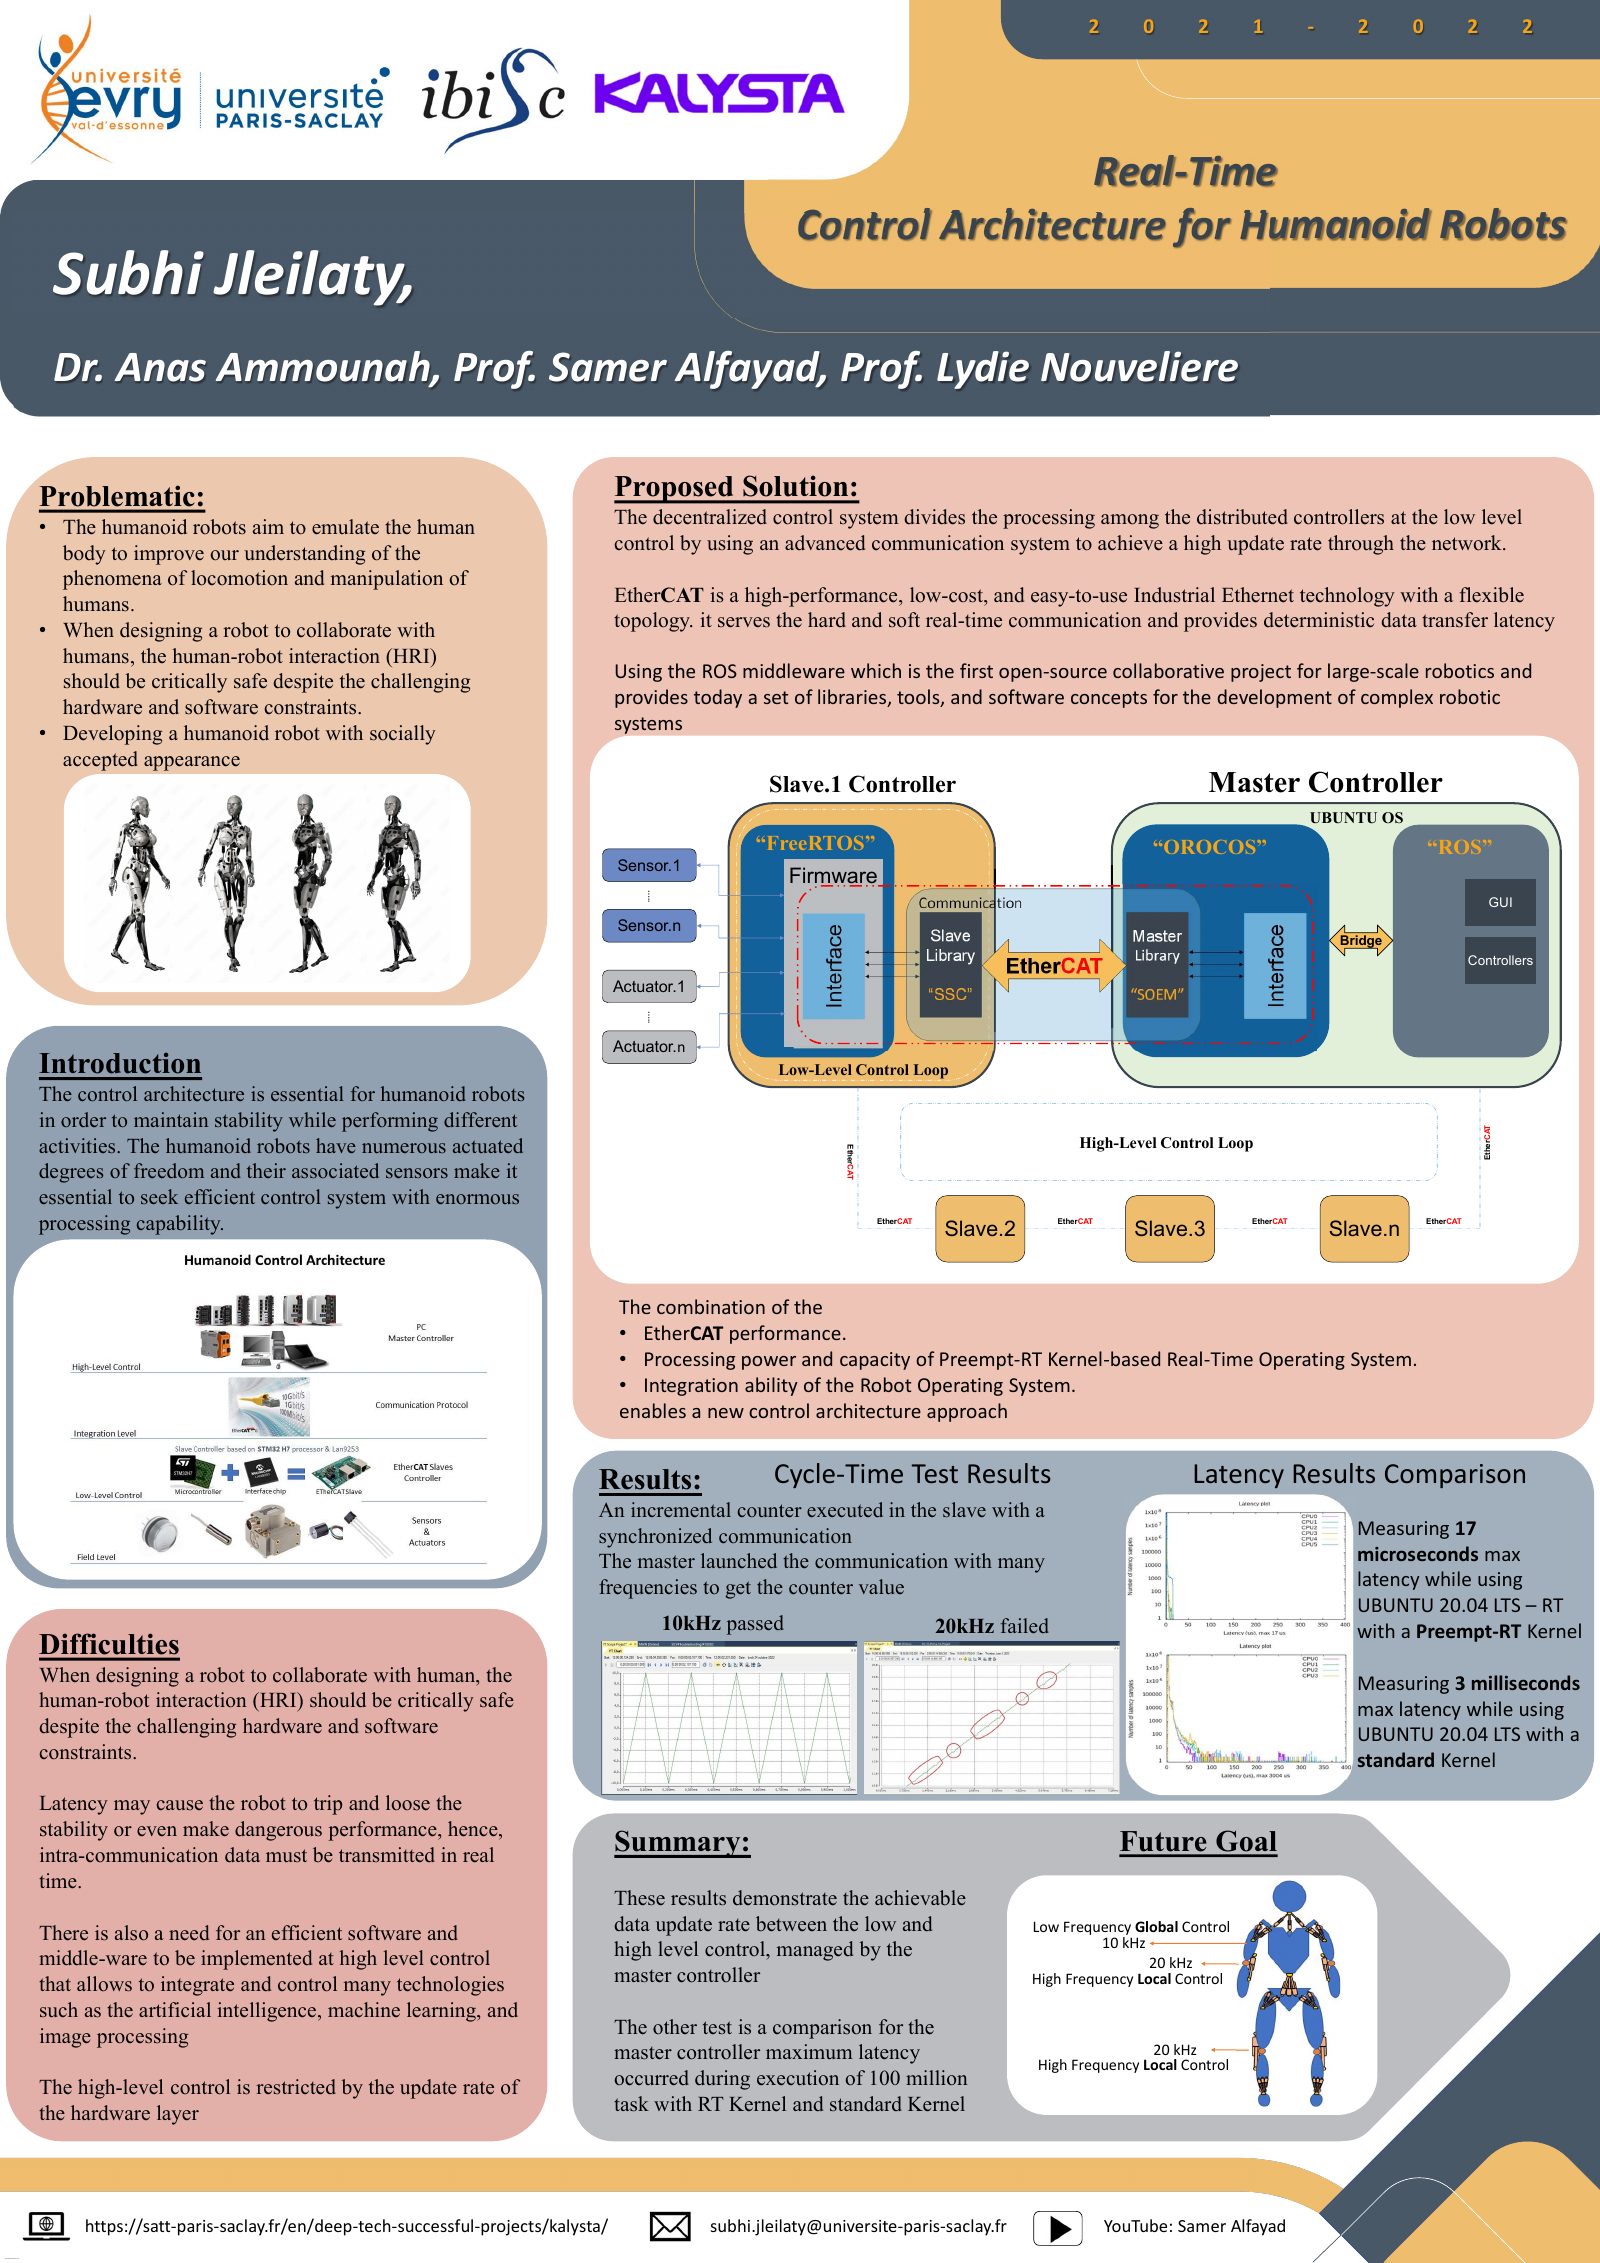
Funded by ANR, full-size humanoid robot from Aldebaran Robotics, in collaboration with LIRMM, CEA and LISV. Responsible for the development of the integrated electro-hydraulically actuated elbow joint.
IN THE LAB
Robotics and mechatronics demonstrations from the laboratory.
VISUAL ARCHIVE
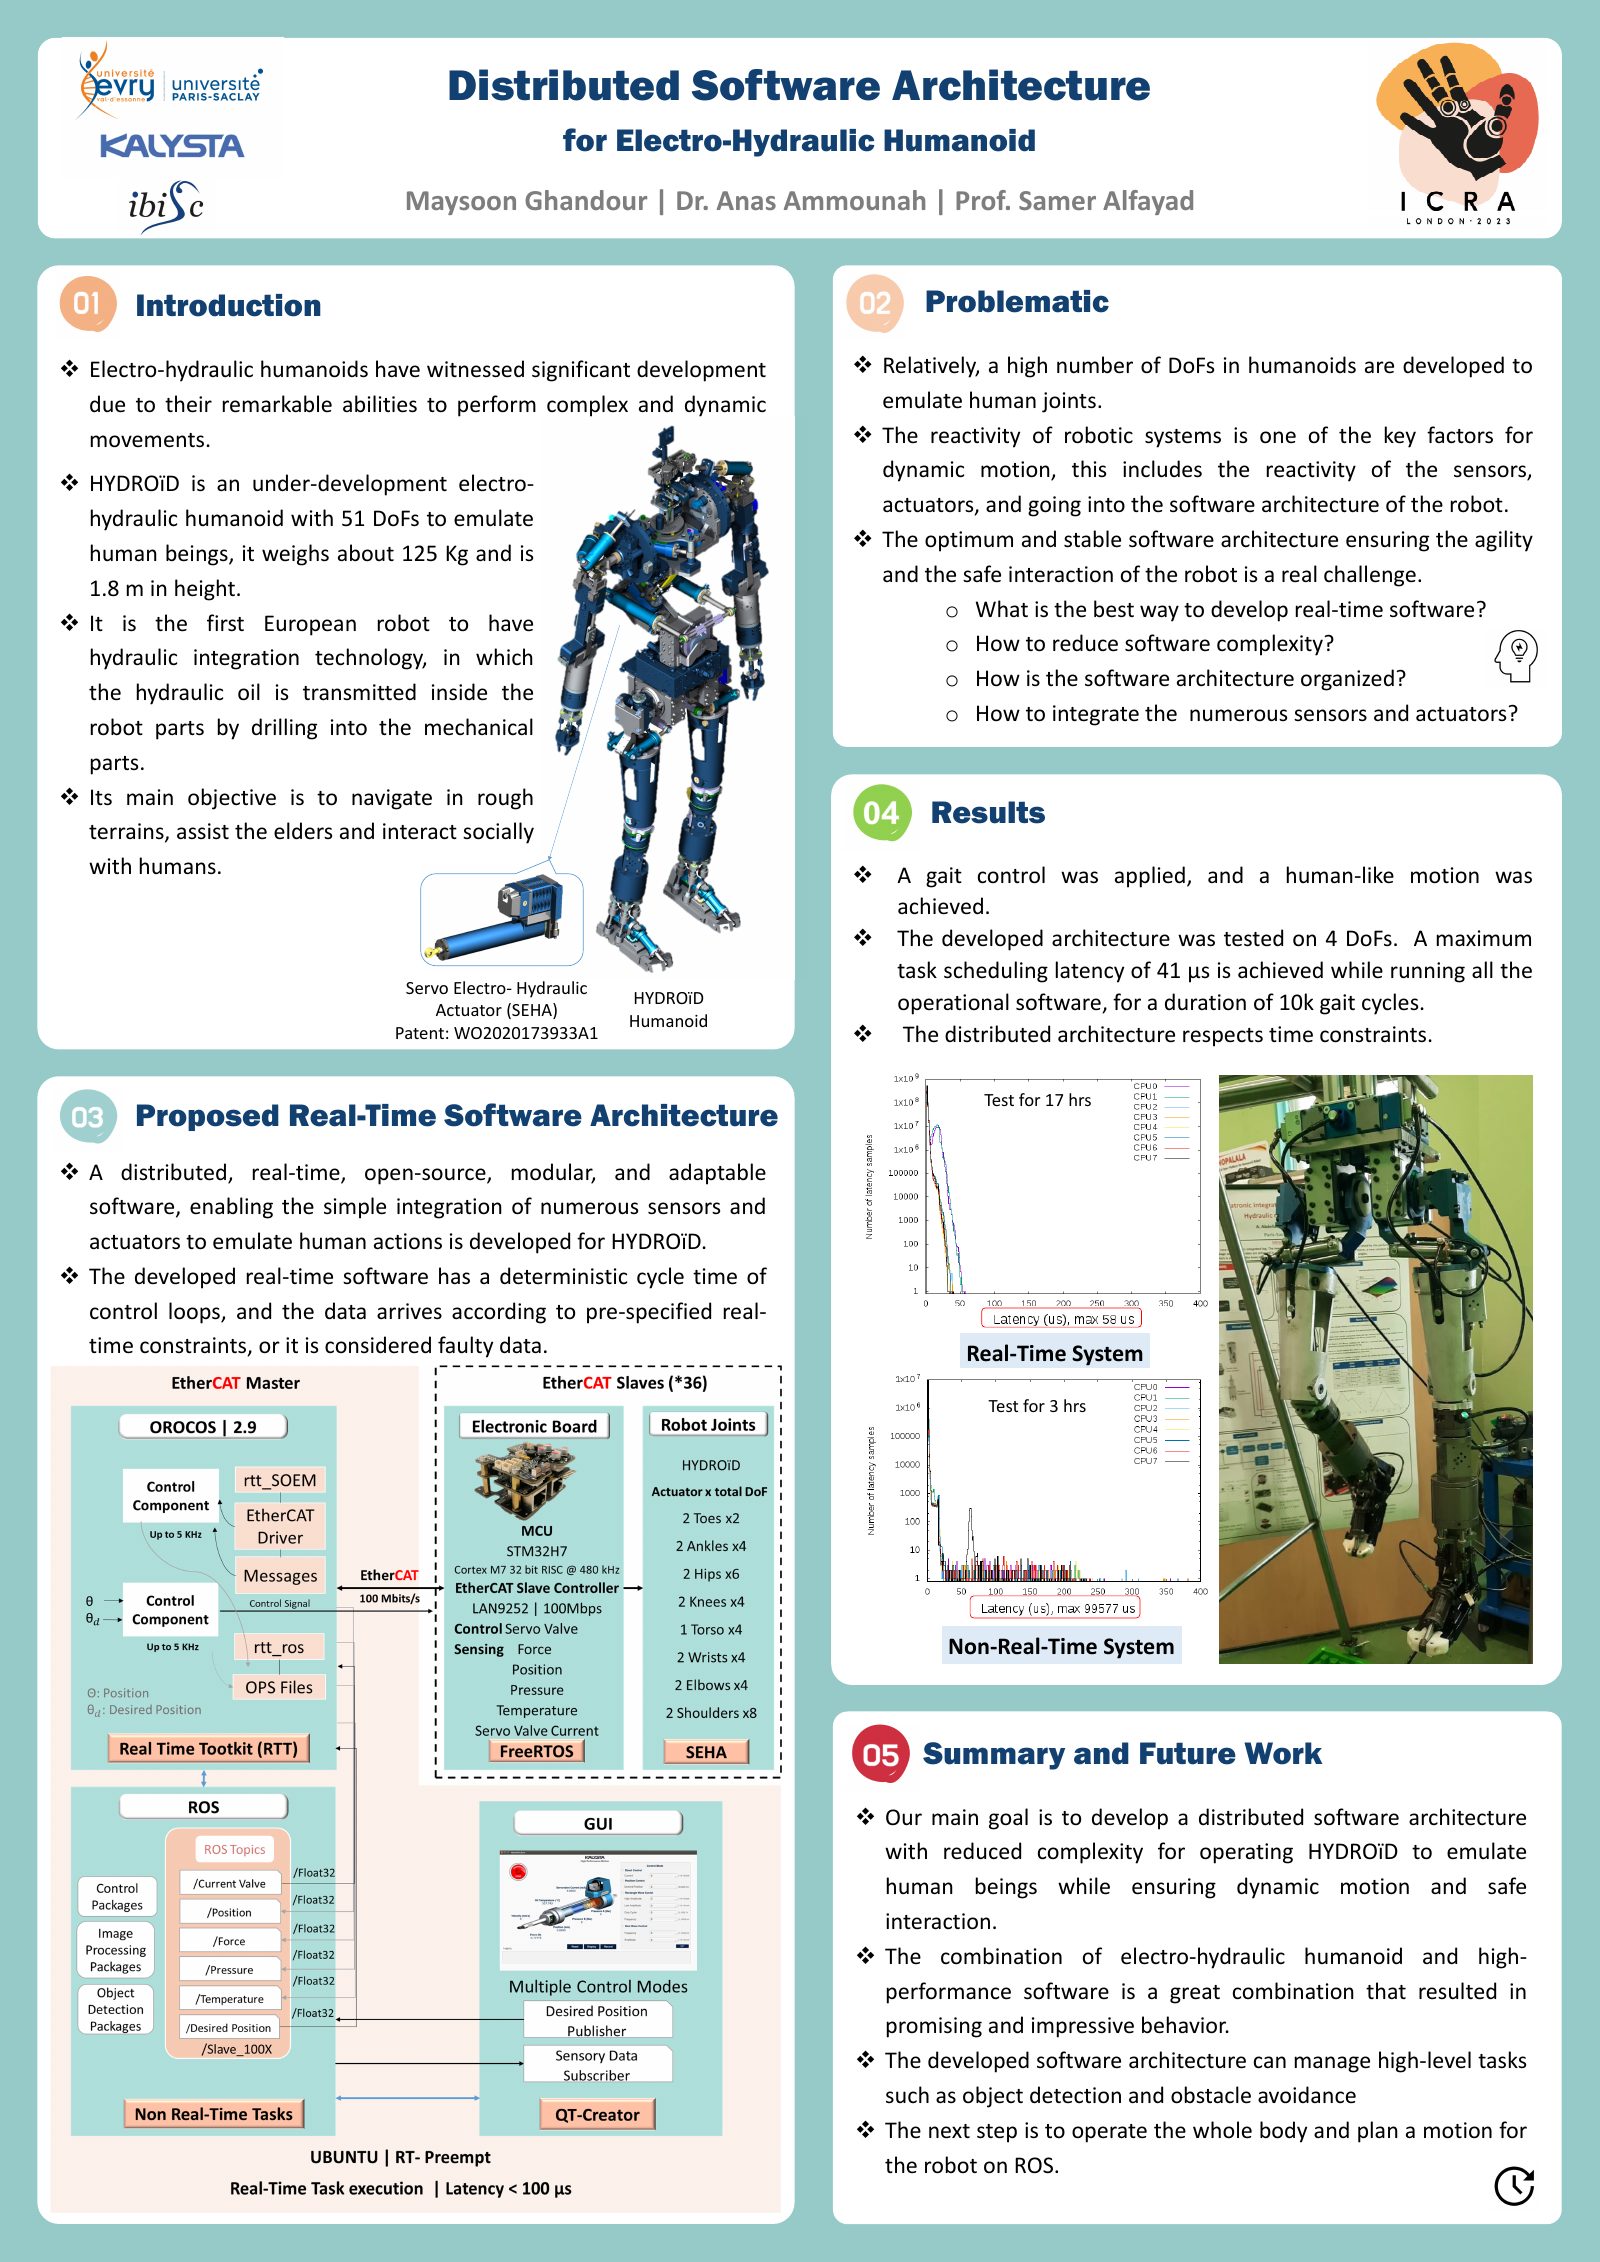
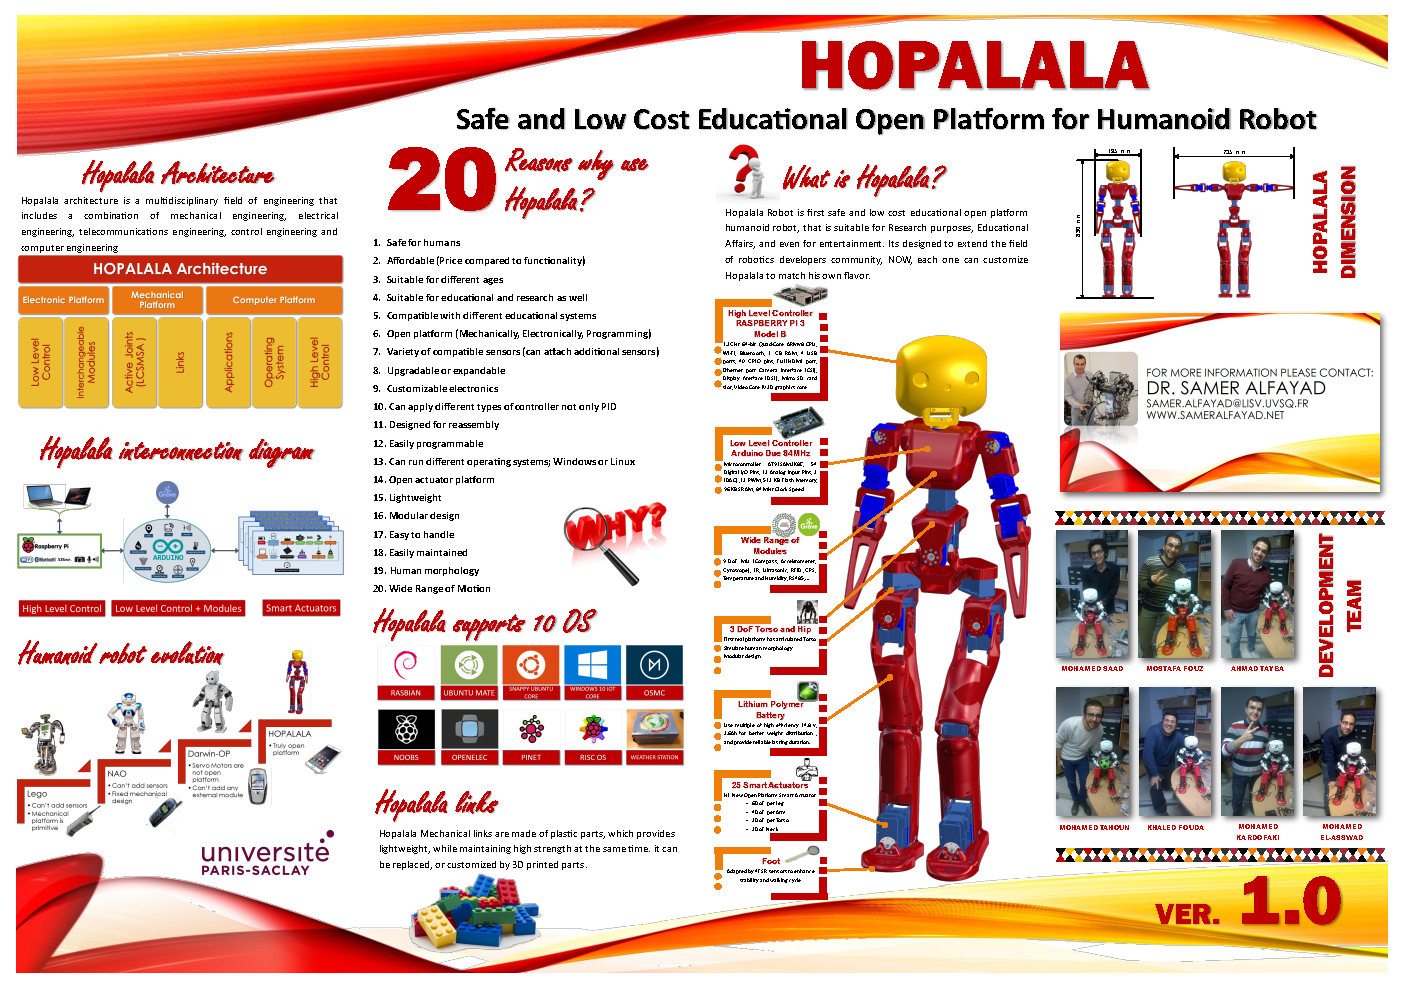
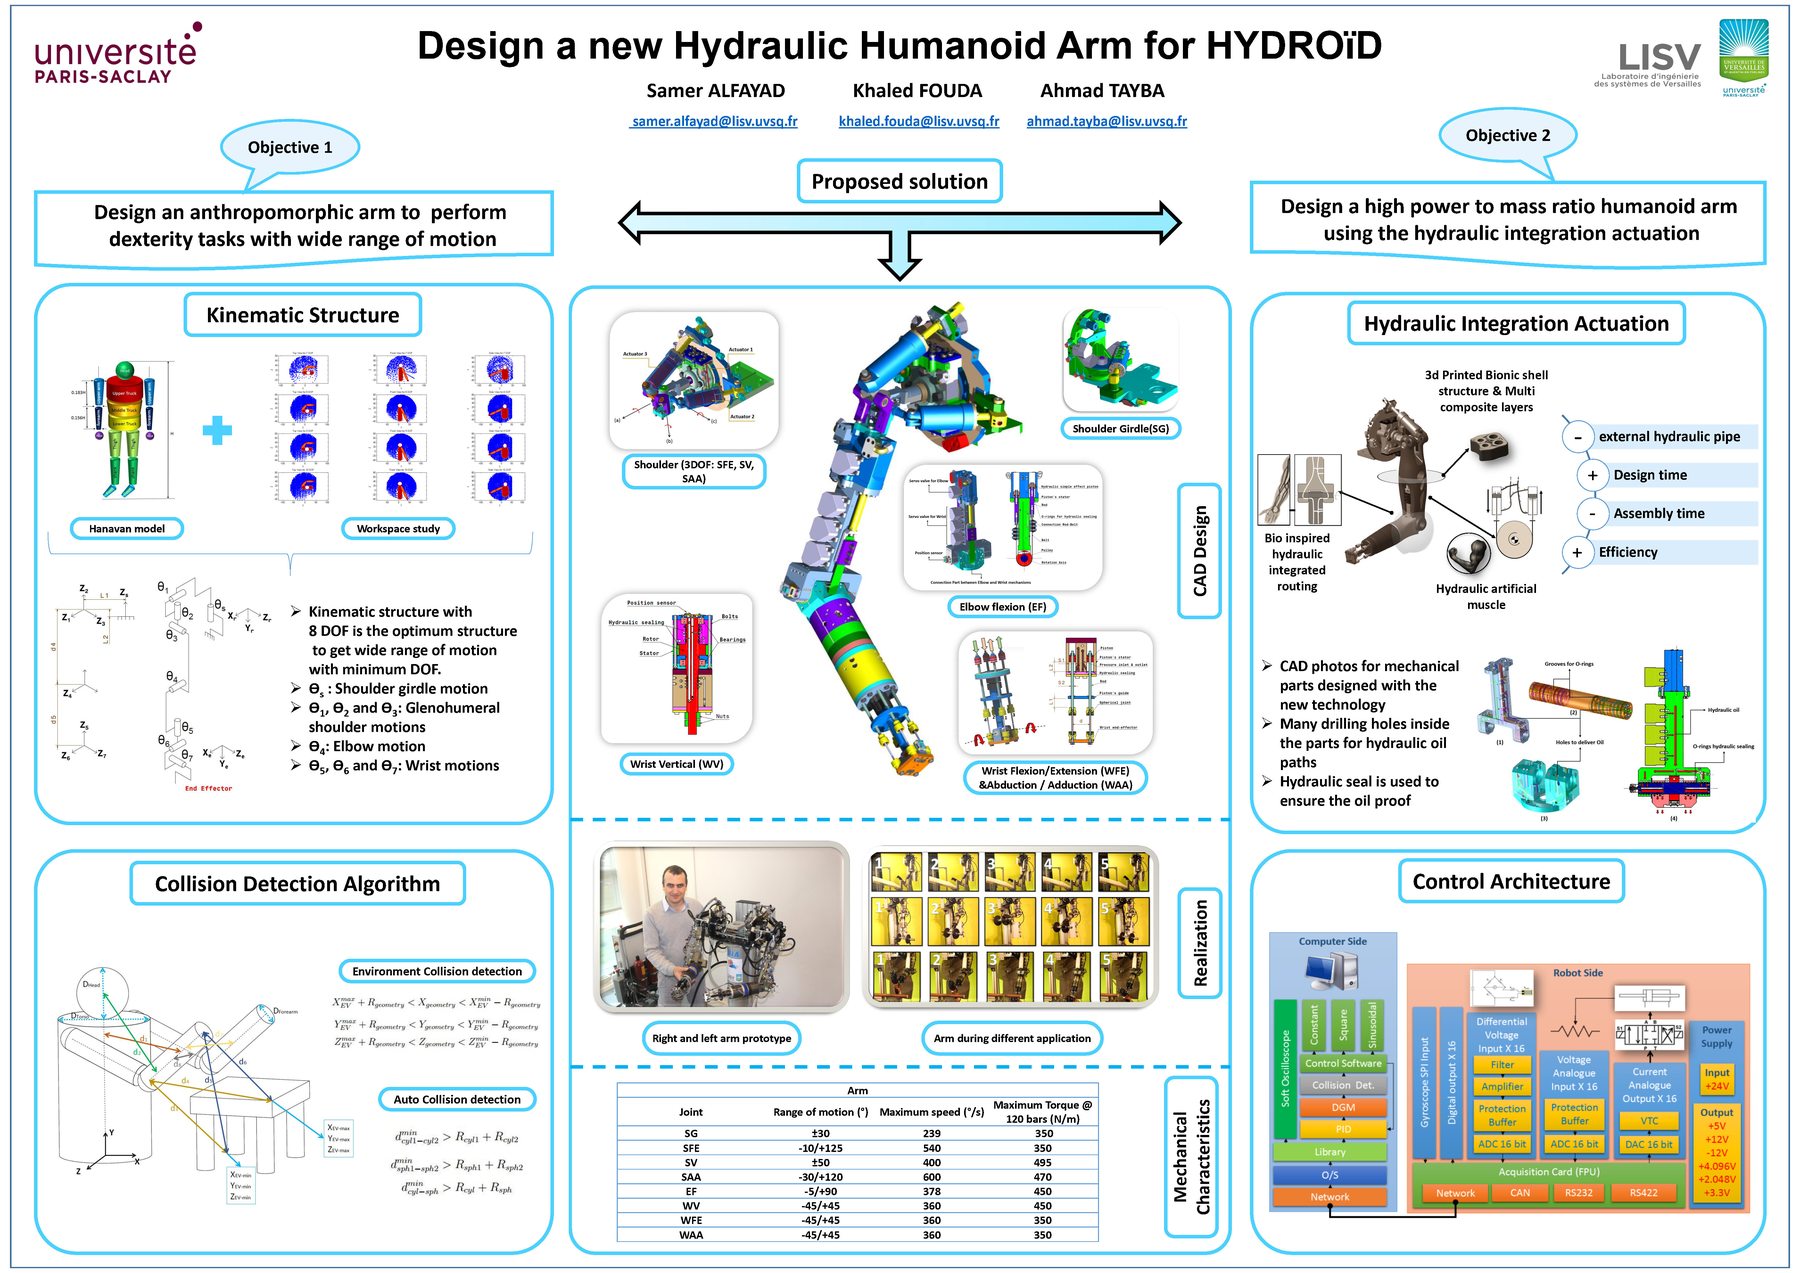
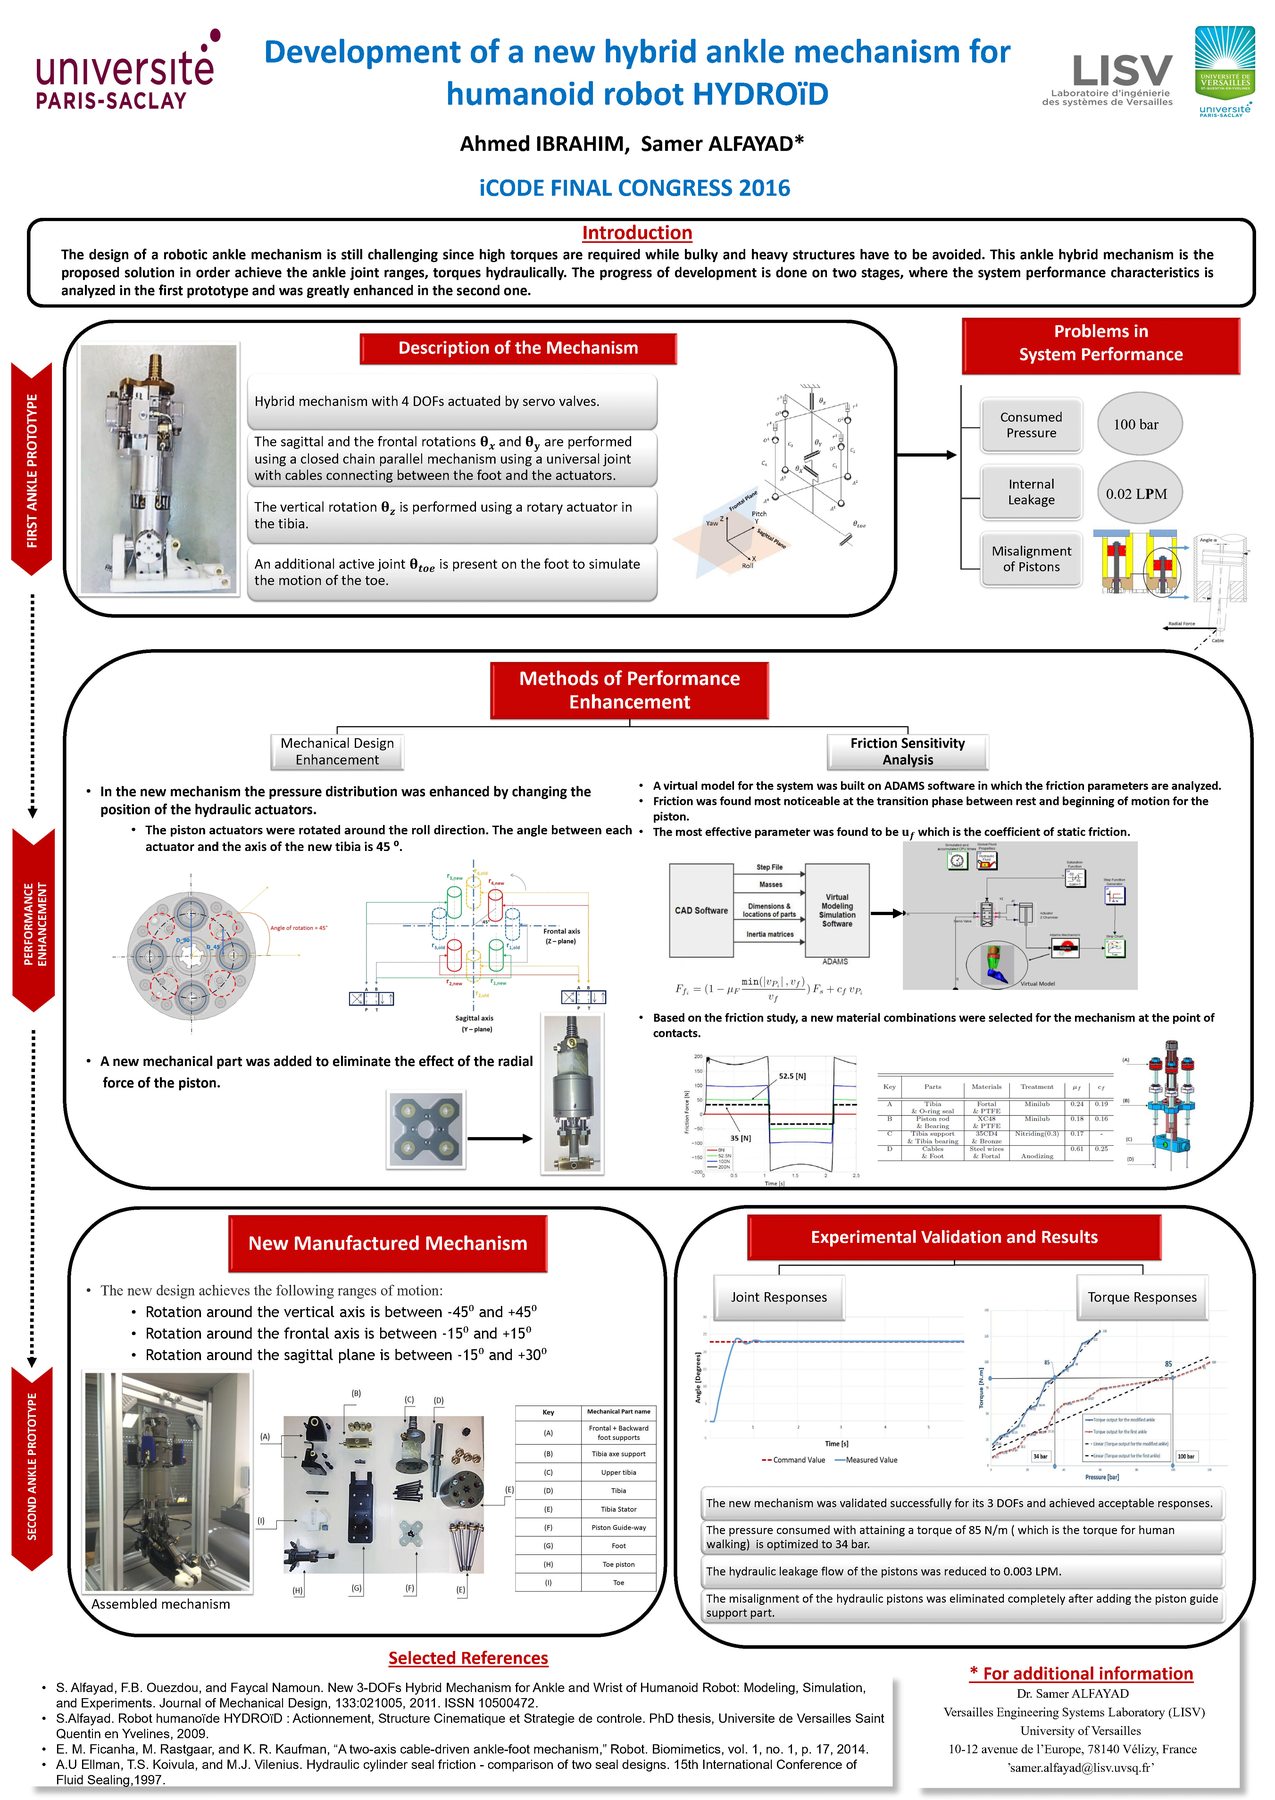
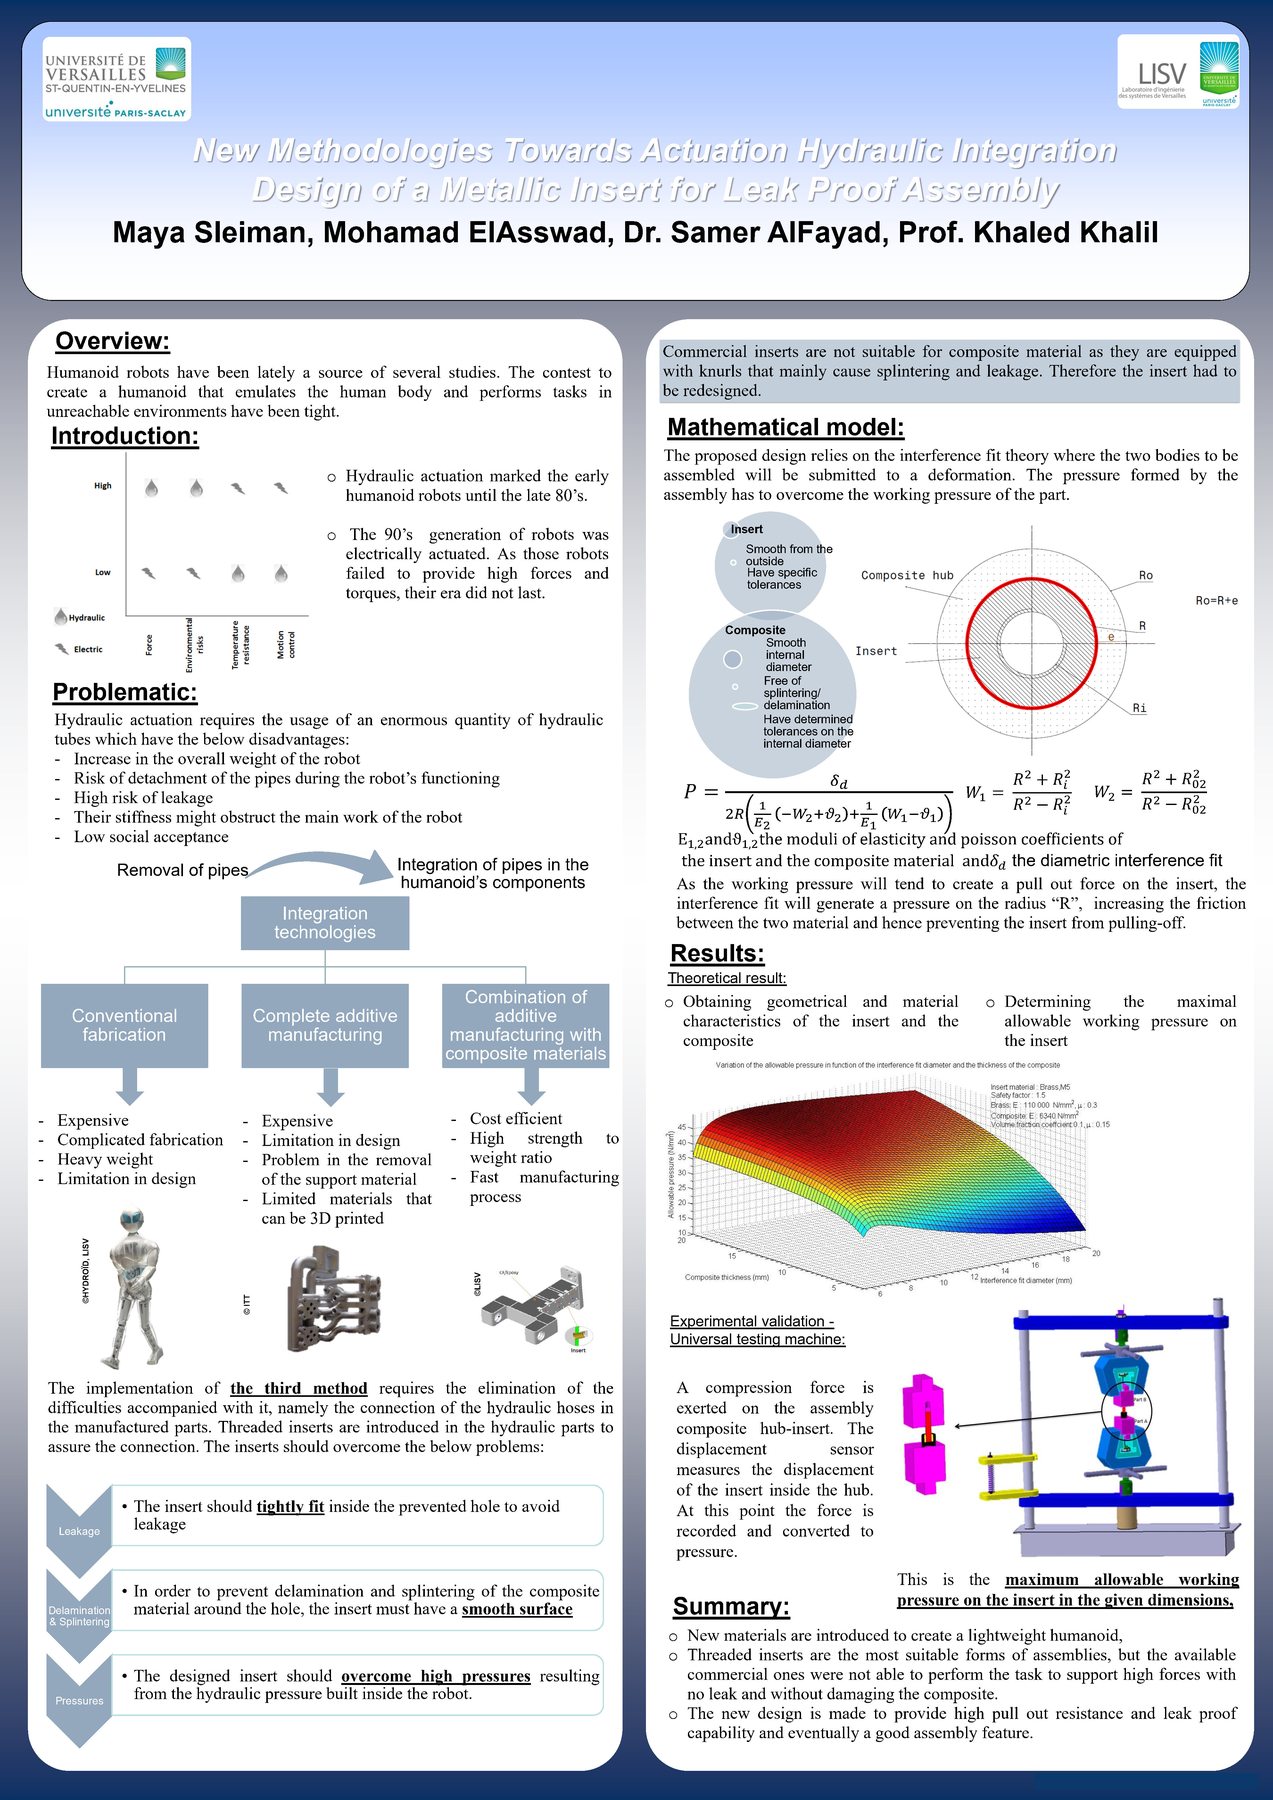
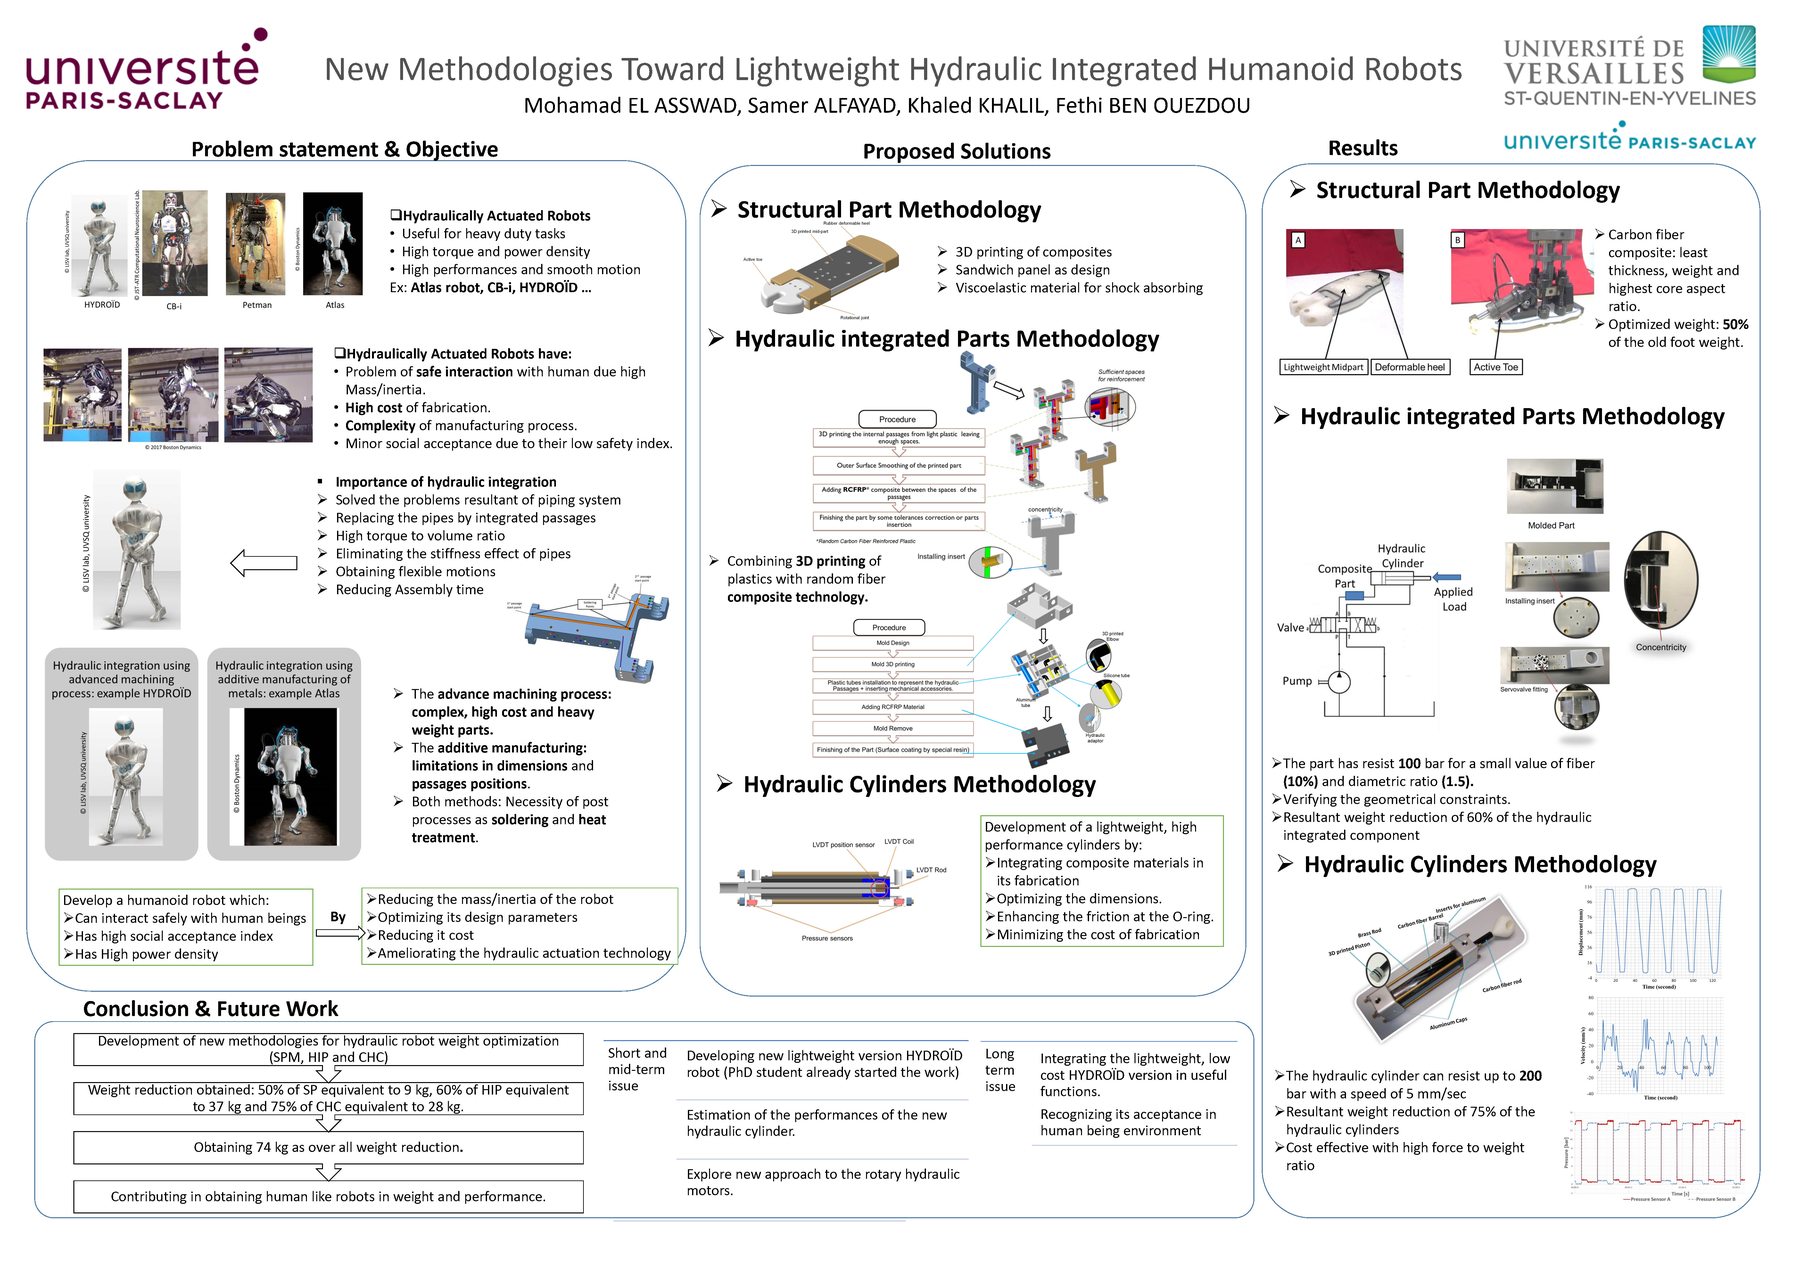
Project photography and research posters.
PATENTS
Illustrated patent records covering actuation, robotic mechanisms and mobility. The research portfolio comprises 53 international patent publications across ten families.
Explore all patents on Google Patents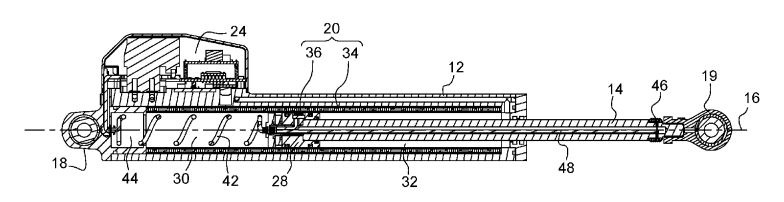
Inventors: ALFAYAD Samer, KARDOFAKI Mohamad, SLEIMAN Maya, ARLOT Romain
Published: 2022 – WO2023088972A1 (also US 18/711,493 – US20250020490A1, 2025)
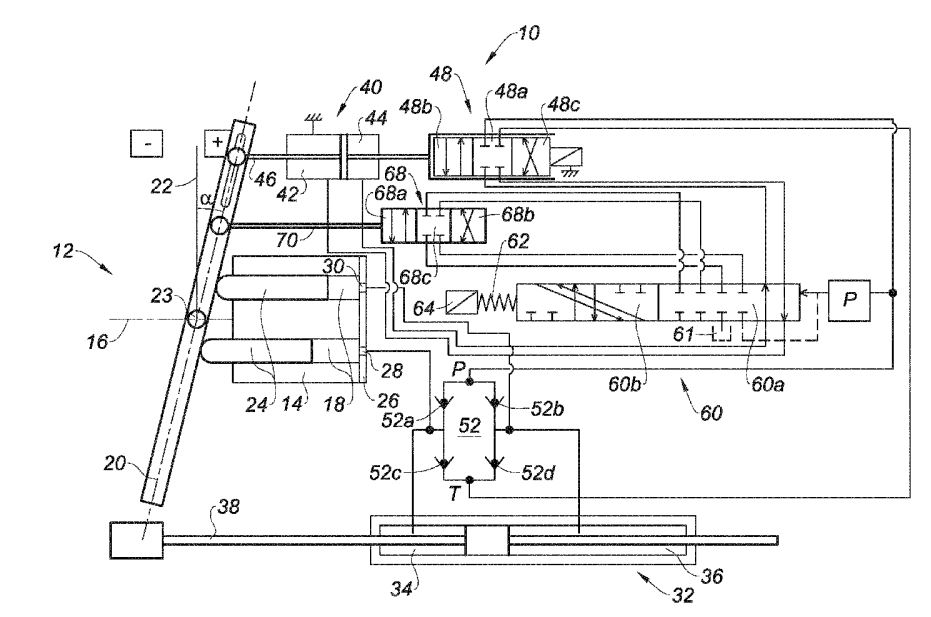
Inventors: ALFAYAD Samer, KARDOFAKI Mohamad, SLEIMAN Maya
Published: 2020 – WO2020173933A1 (EP3931444A1, DE2070 5749.8, CN113454338A, FR3093138A1)
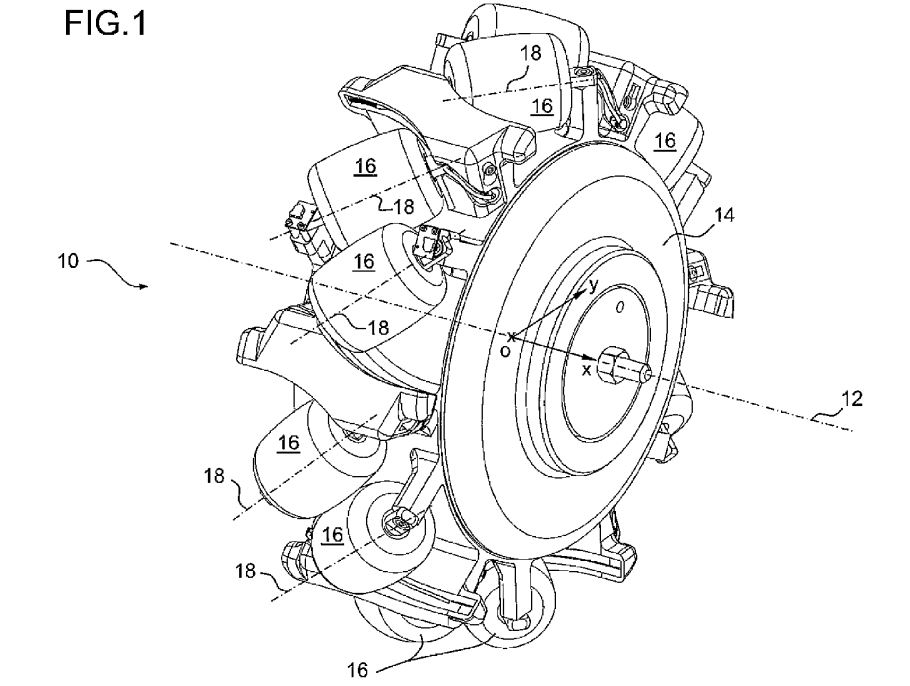
Inventors: ALFAYAD Samer, KARDOFAKI Mohamad, FOUDA Khaled
Published: 2018 – WO2018158445A1 (EP3589499A1, DE18709327.3, FR3063453B1)
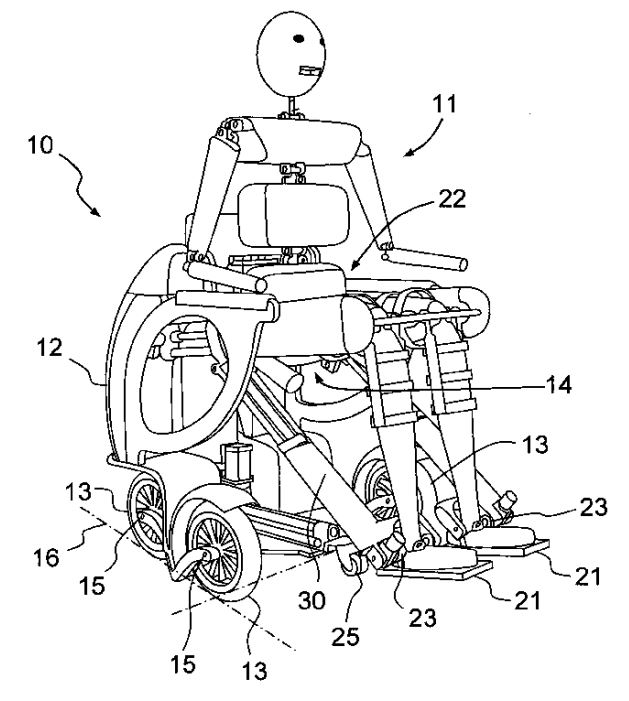
Inventors: ALFAYAD Samer, NAMOUN Fayçal, BEN OUEZDOU Fathi
Published: 2018 – FR3055798A1 (INPI, France)
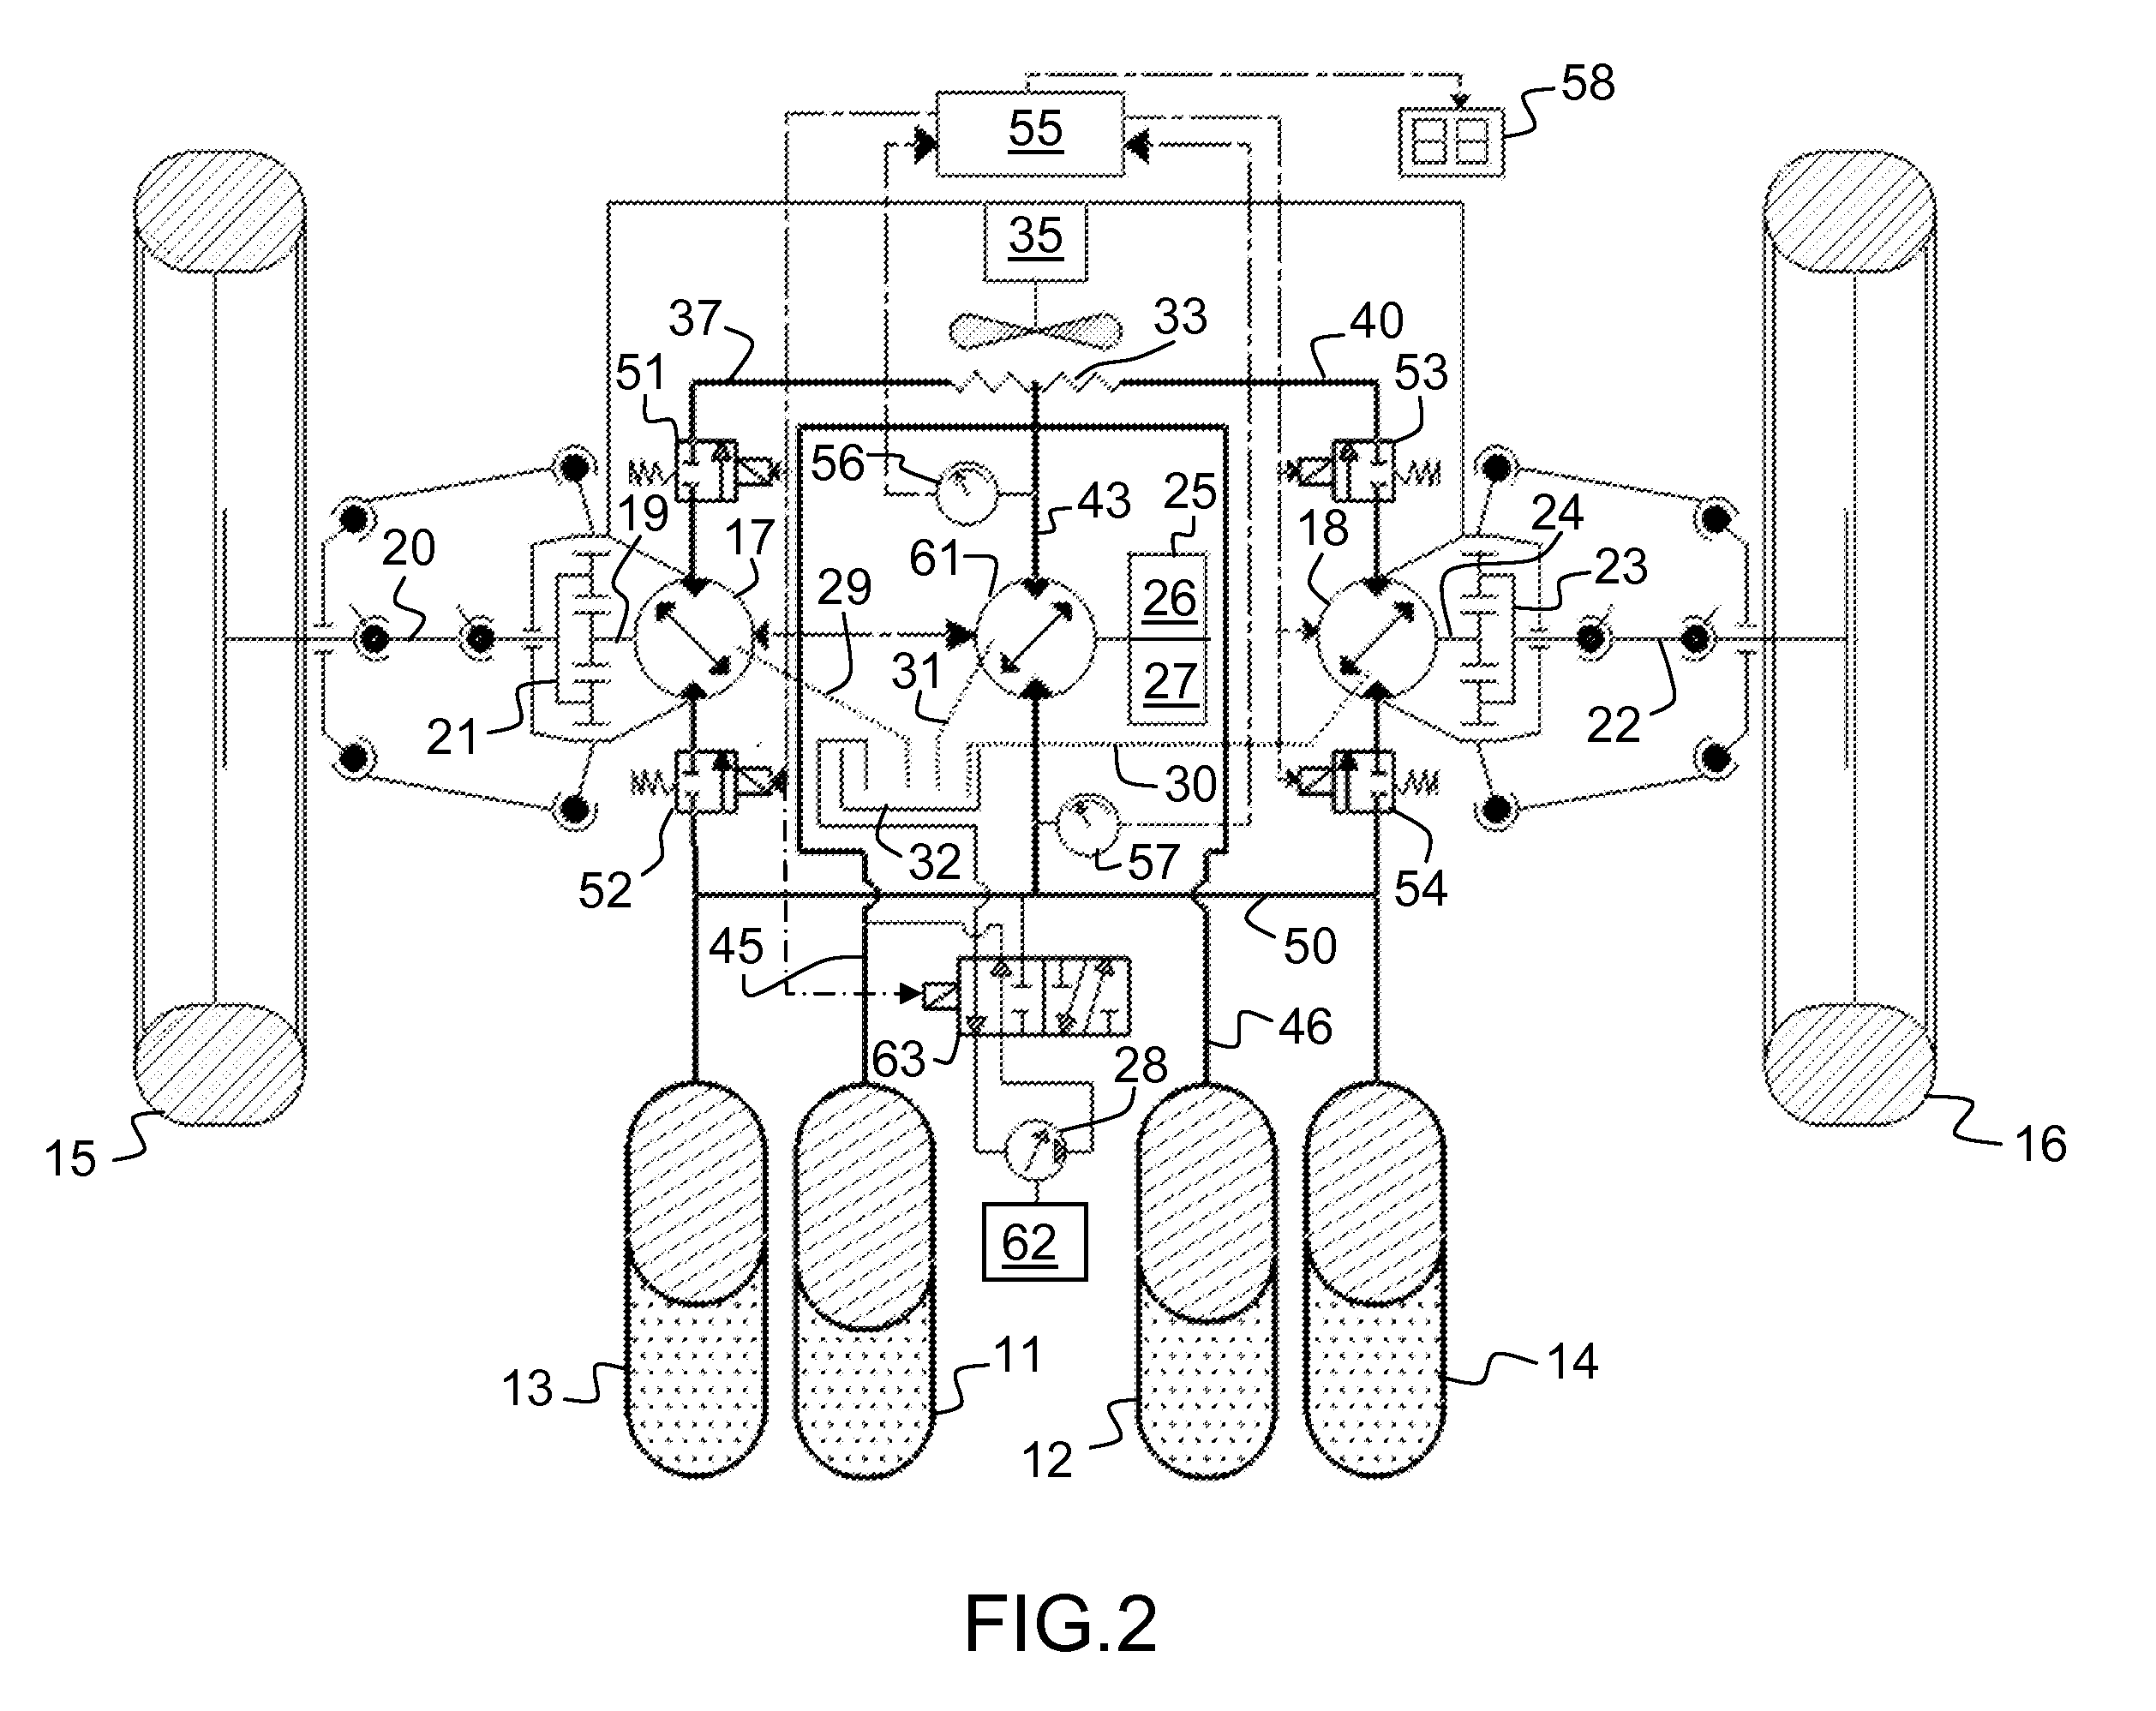
Inventors: NAMOUN Fayçal, BEN OUEZDOU Fathi, ALFAYAD Samer
Published: 01/09/2011 – WO2011104383A1 (FR2956841B1)
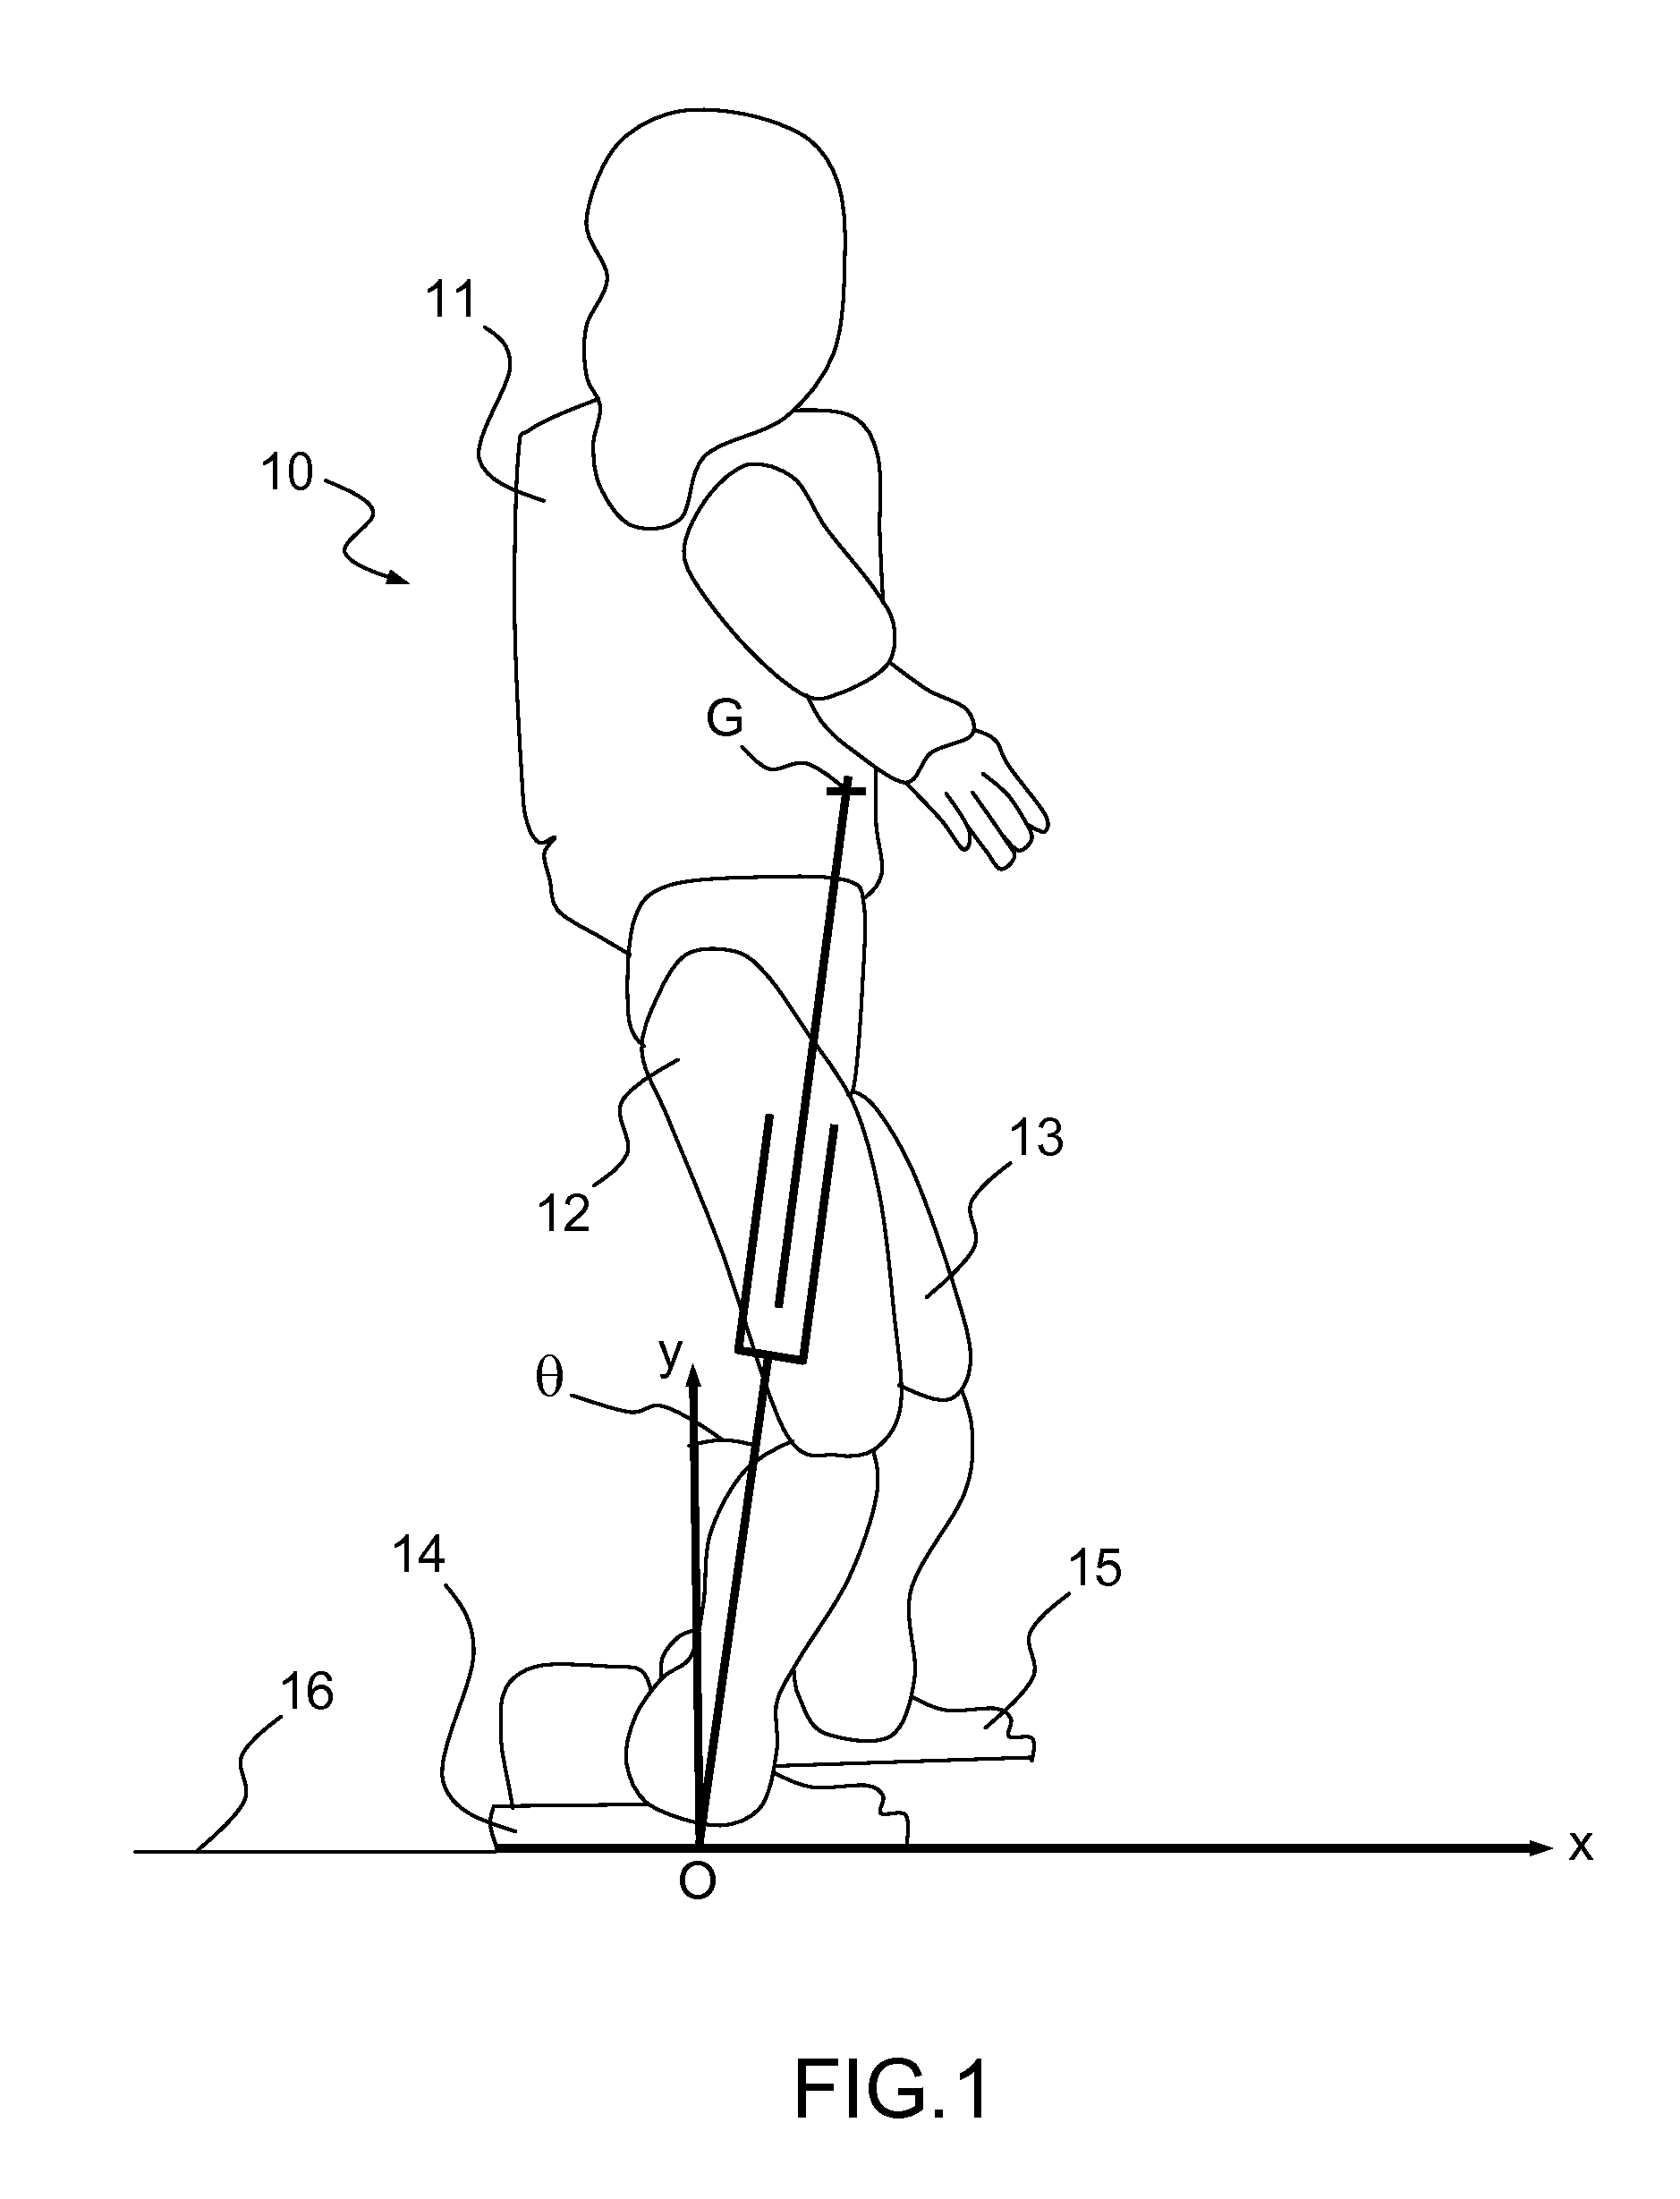
Inventors: ALFAYAD Samer, BRUNEAU Olivier, DOUBLIEZ P.F., BEN OUEZDOU Fathi
Published: 11/11/2010 – WO2010128088A1 (FR2945231B1, DE602010064 911.3)
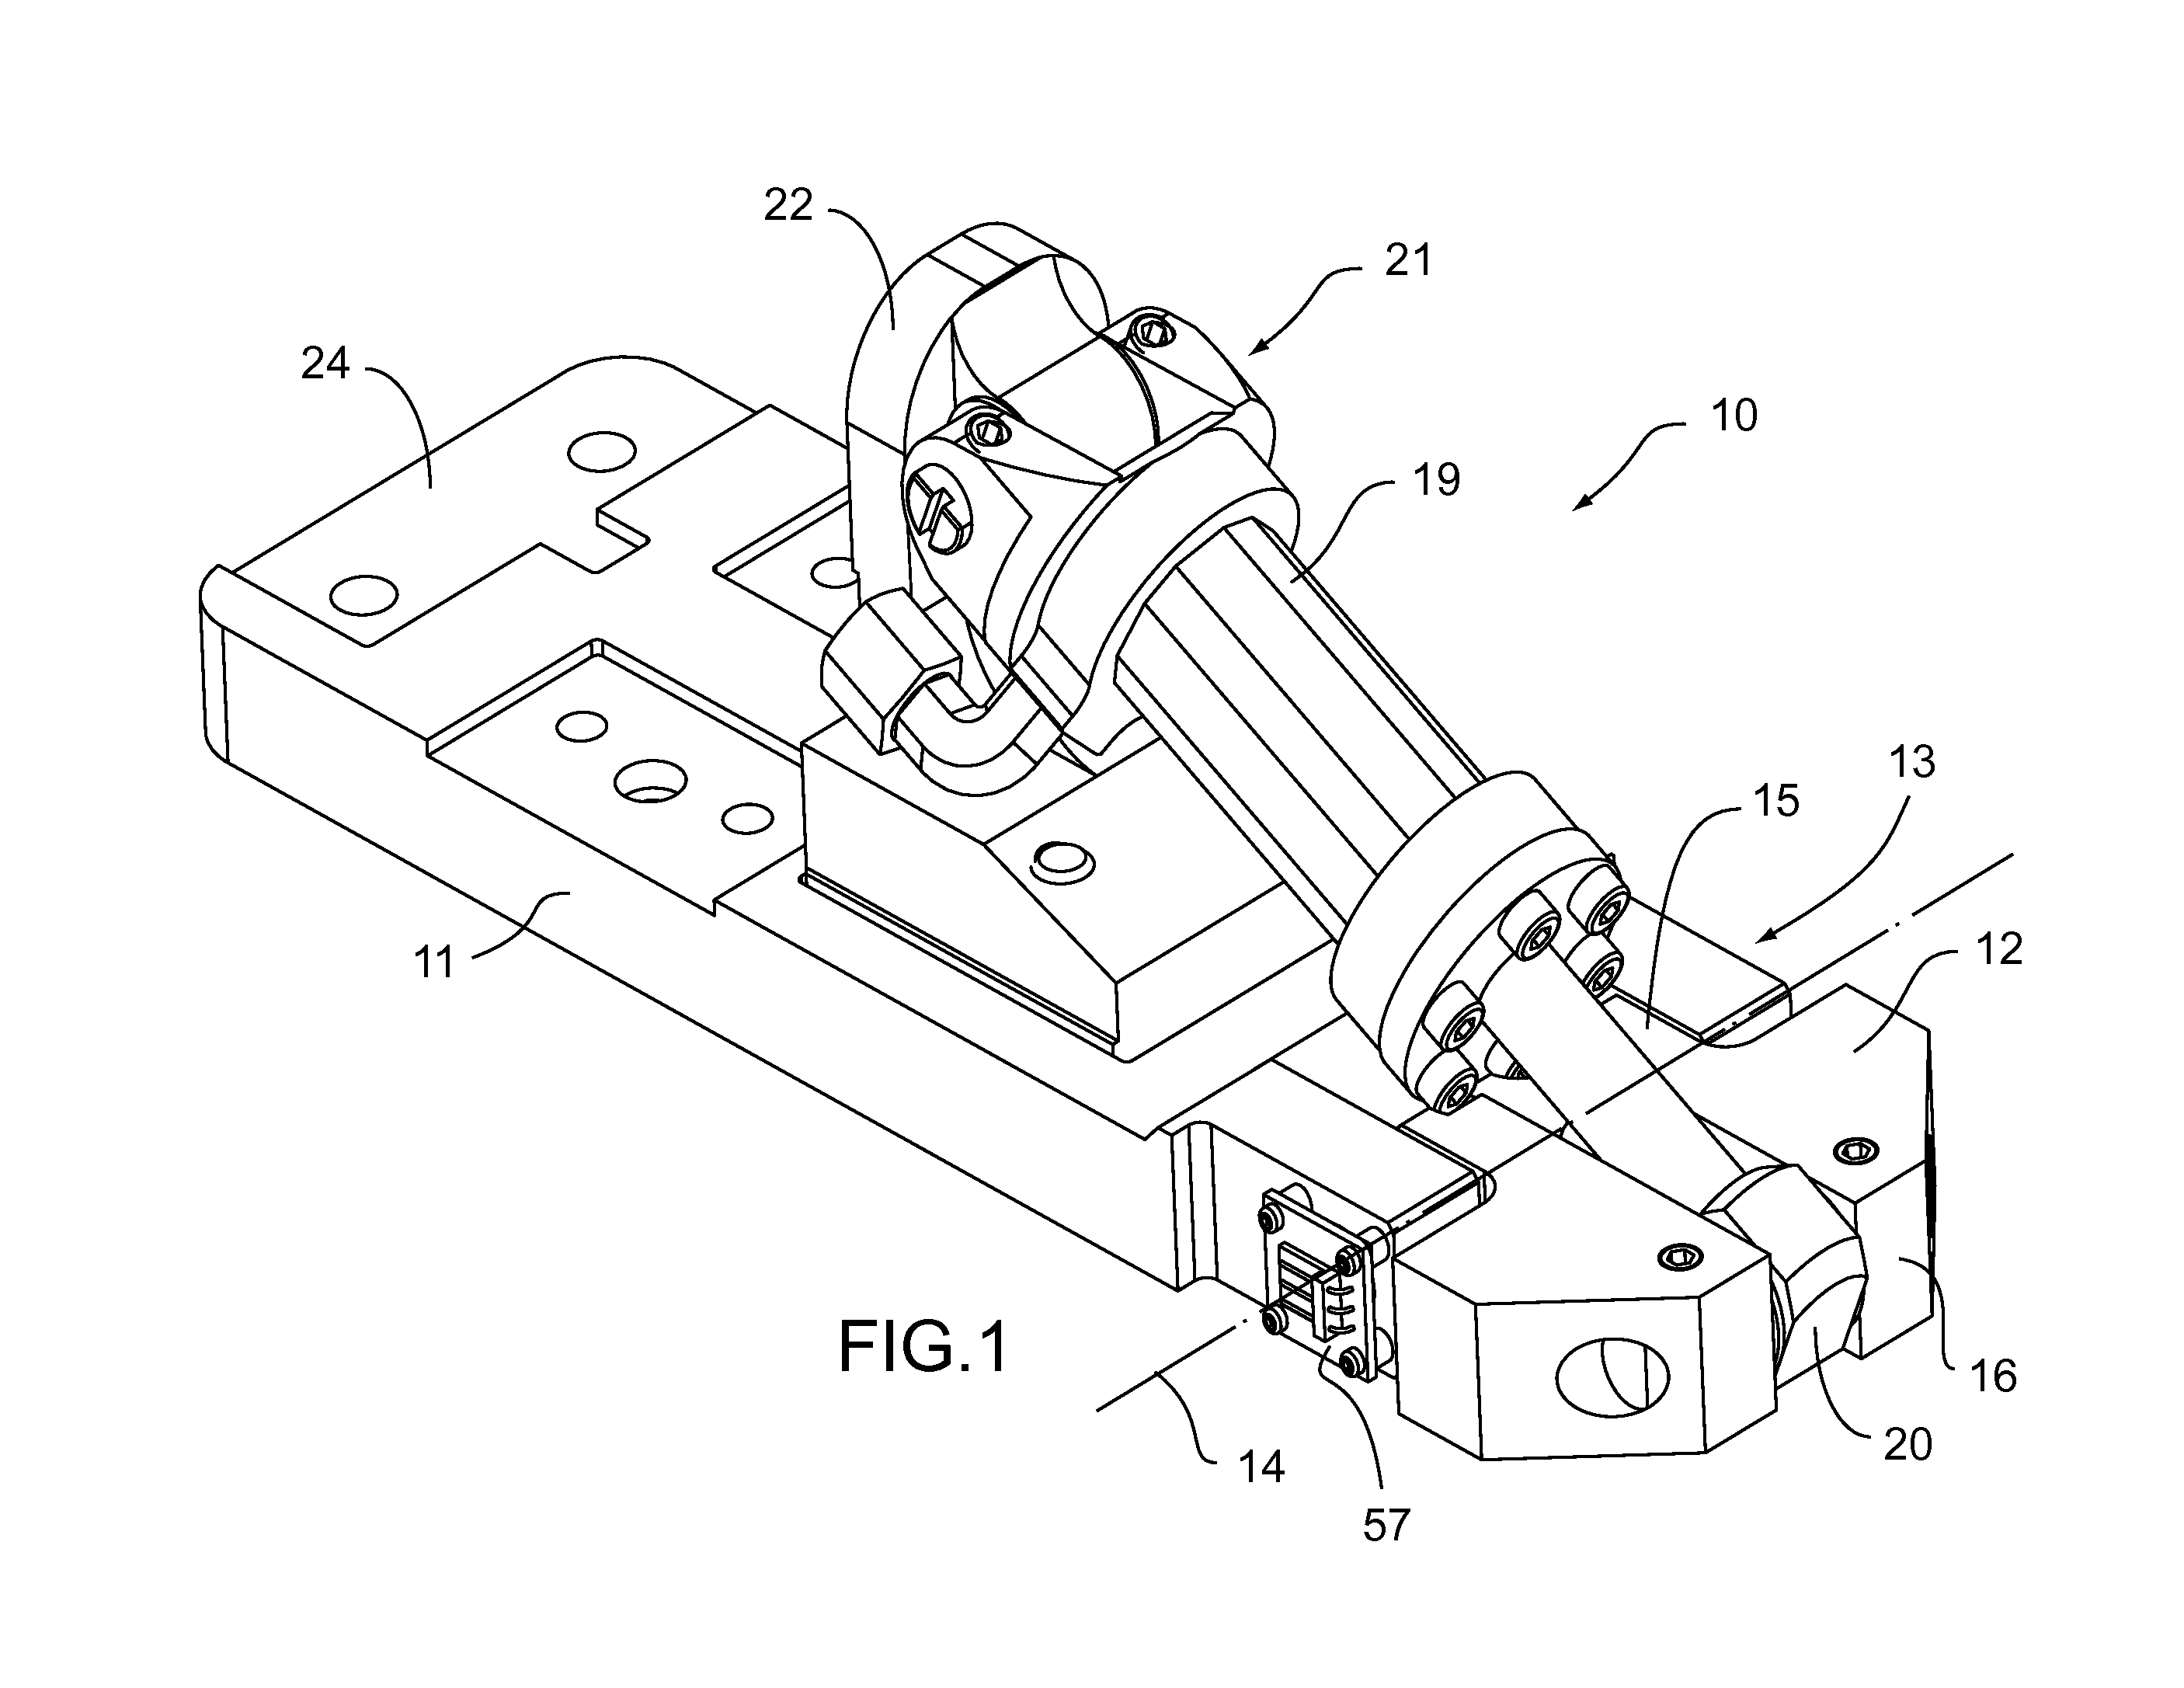
Inventors: ALFAYAD Samer, BEN OUEZDOU Fathi, NAMOUN Fayçal
Published: 10/12/2009 – WO2009147243A1 (US8403081B2, EP2321170B1, JP5987316B2, ES2391612T3, FR2932110B1)
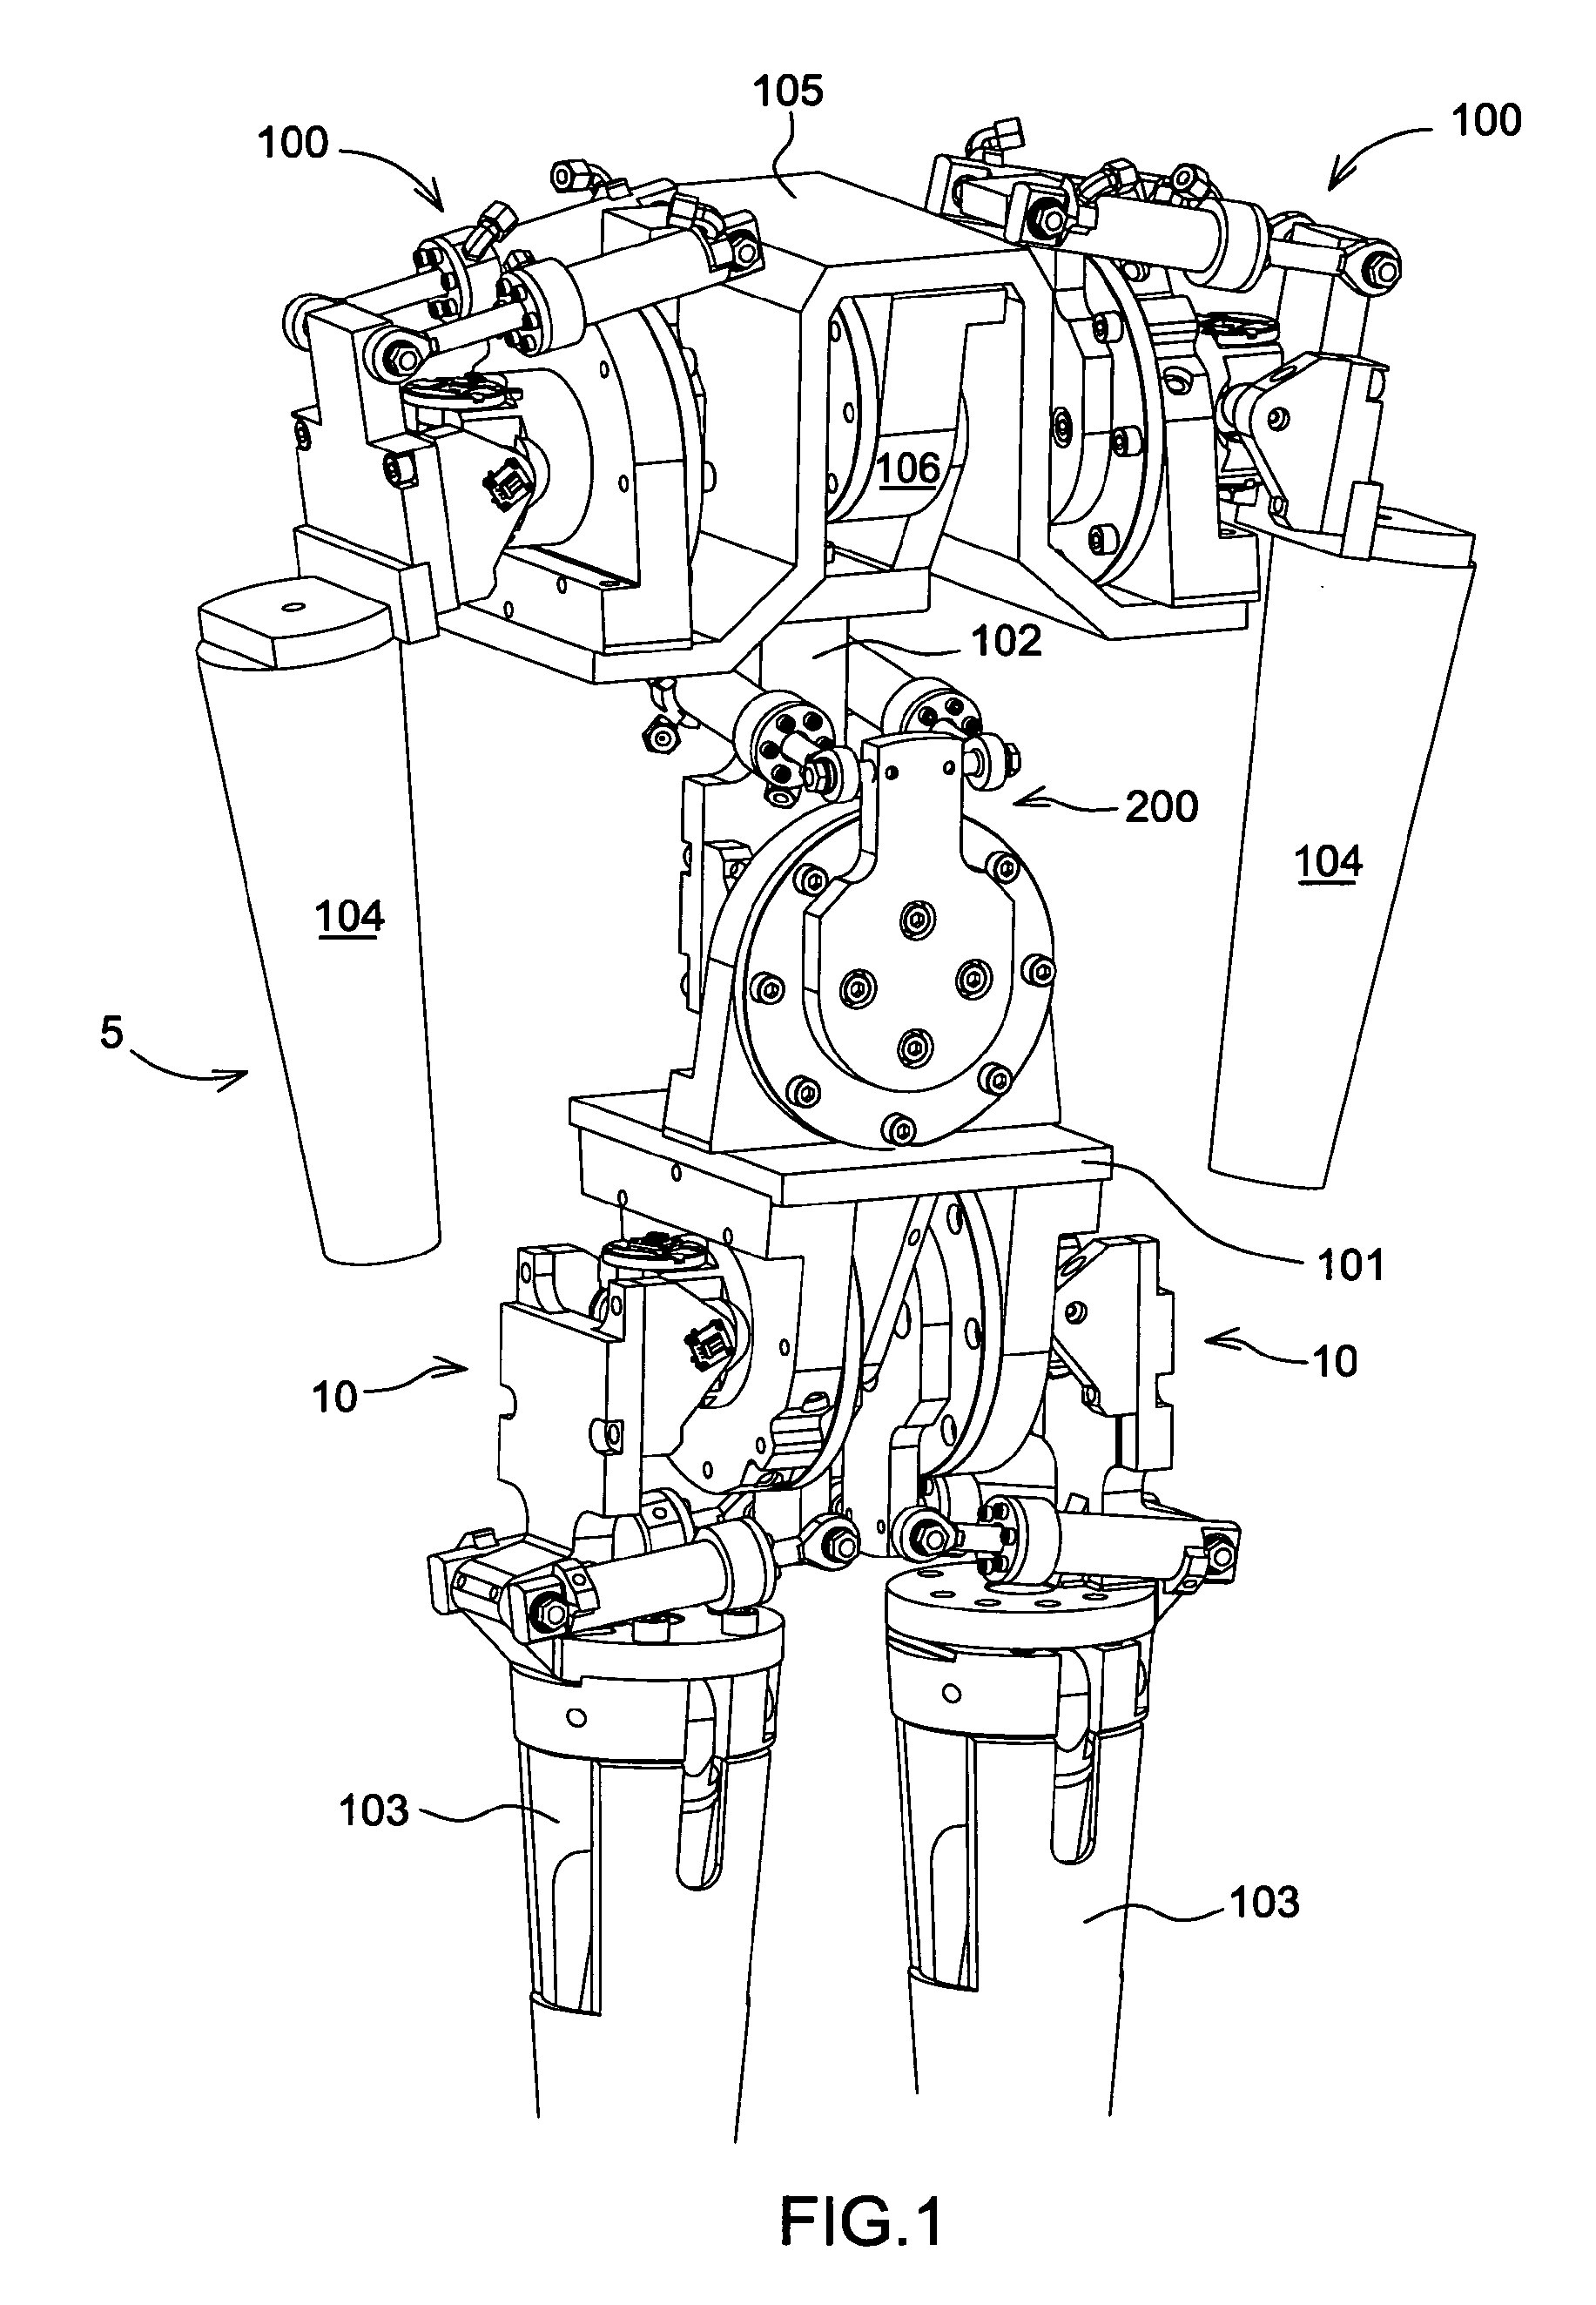
Inventors: ALFAYAD Samer, BEN OUEZDOU Fathi, NAMOUN Fayçal
Published: 03/12/2009 – WO2009144320A1 (US8875594B2, EP2313304B1, JP5879650B2, ES2382307T3)
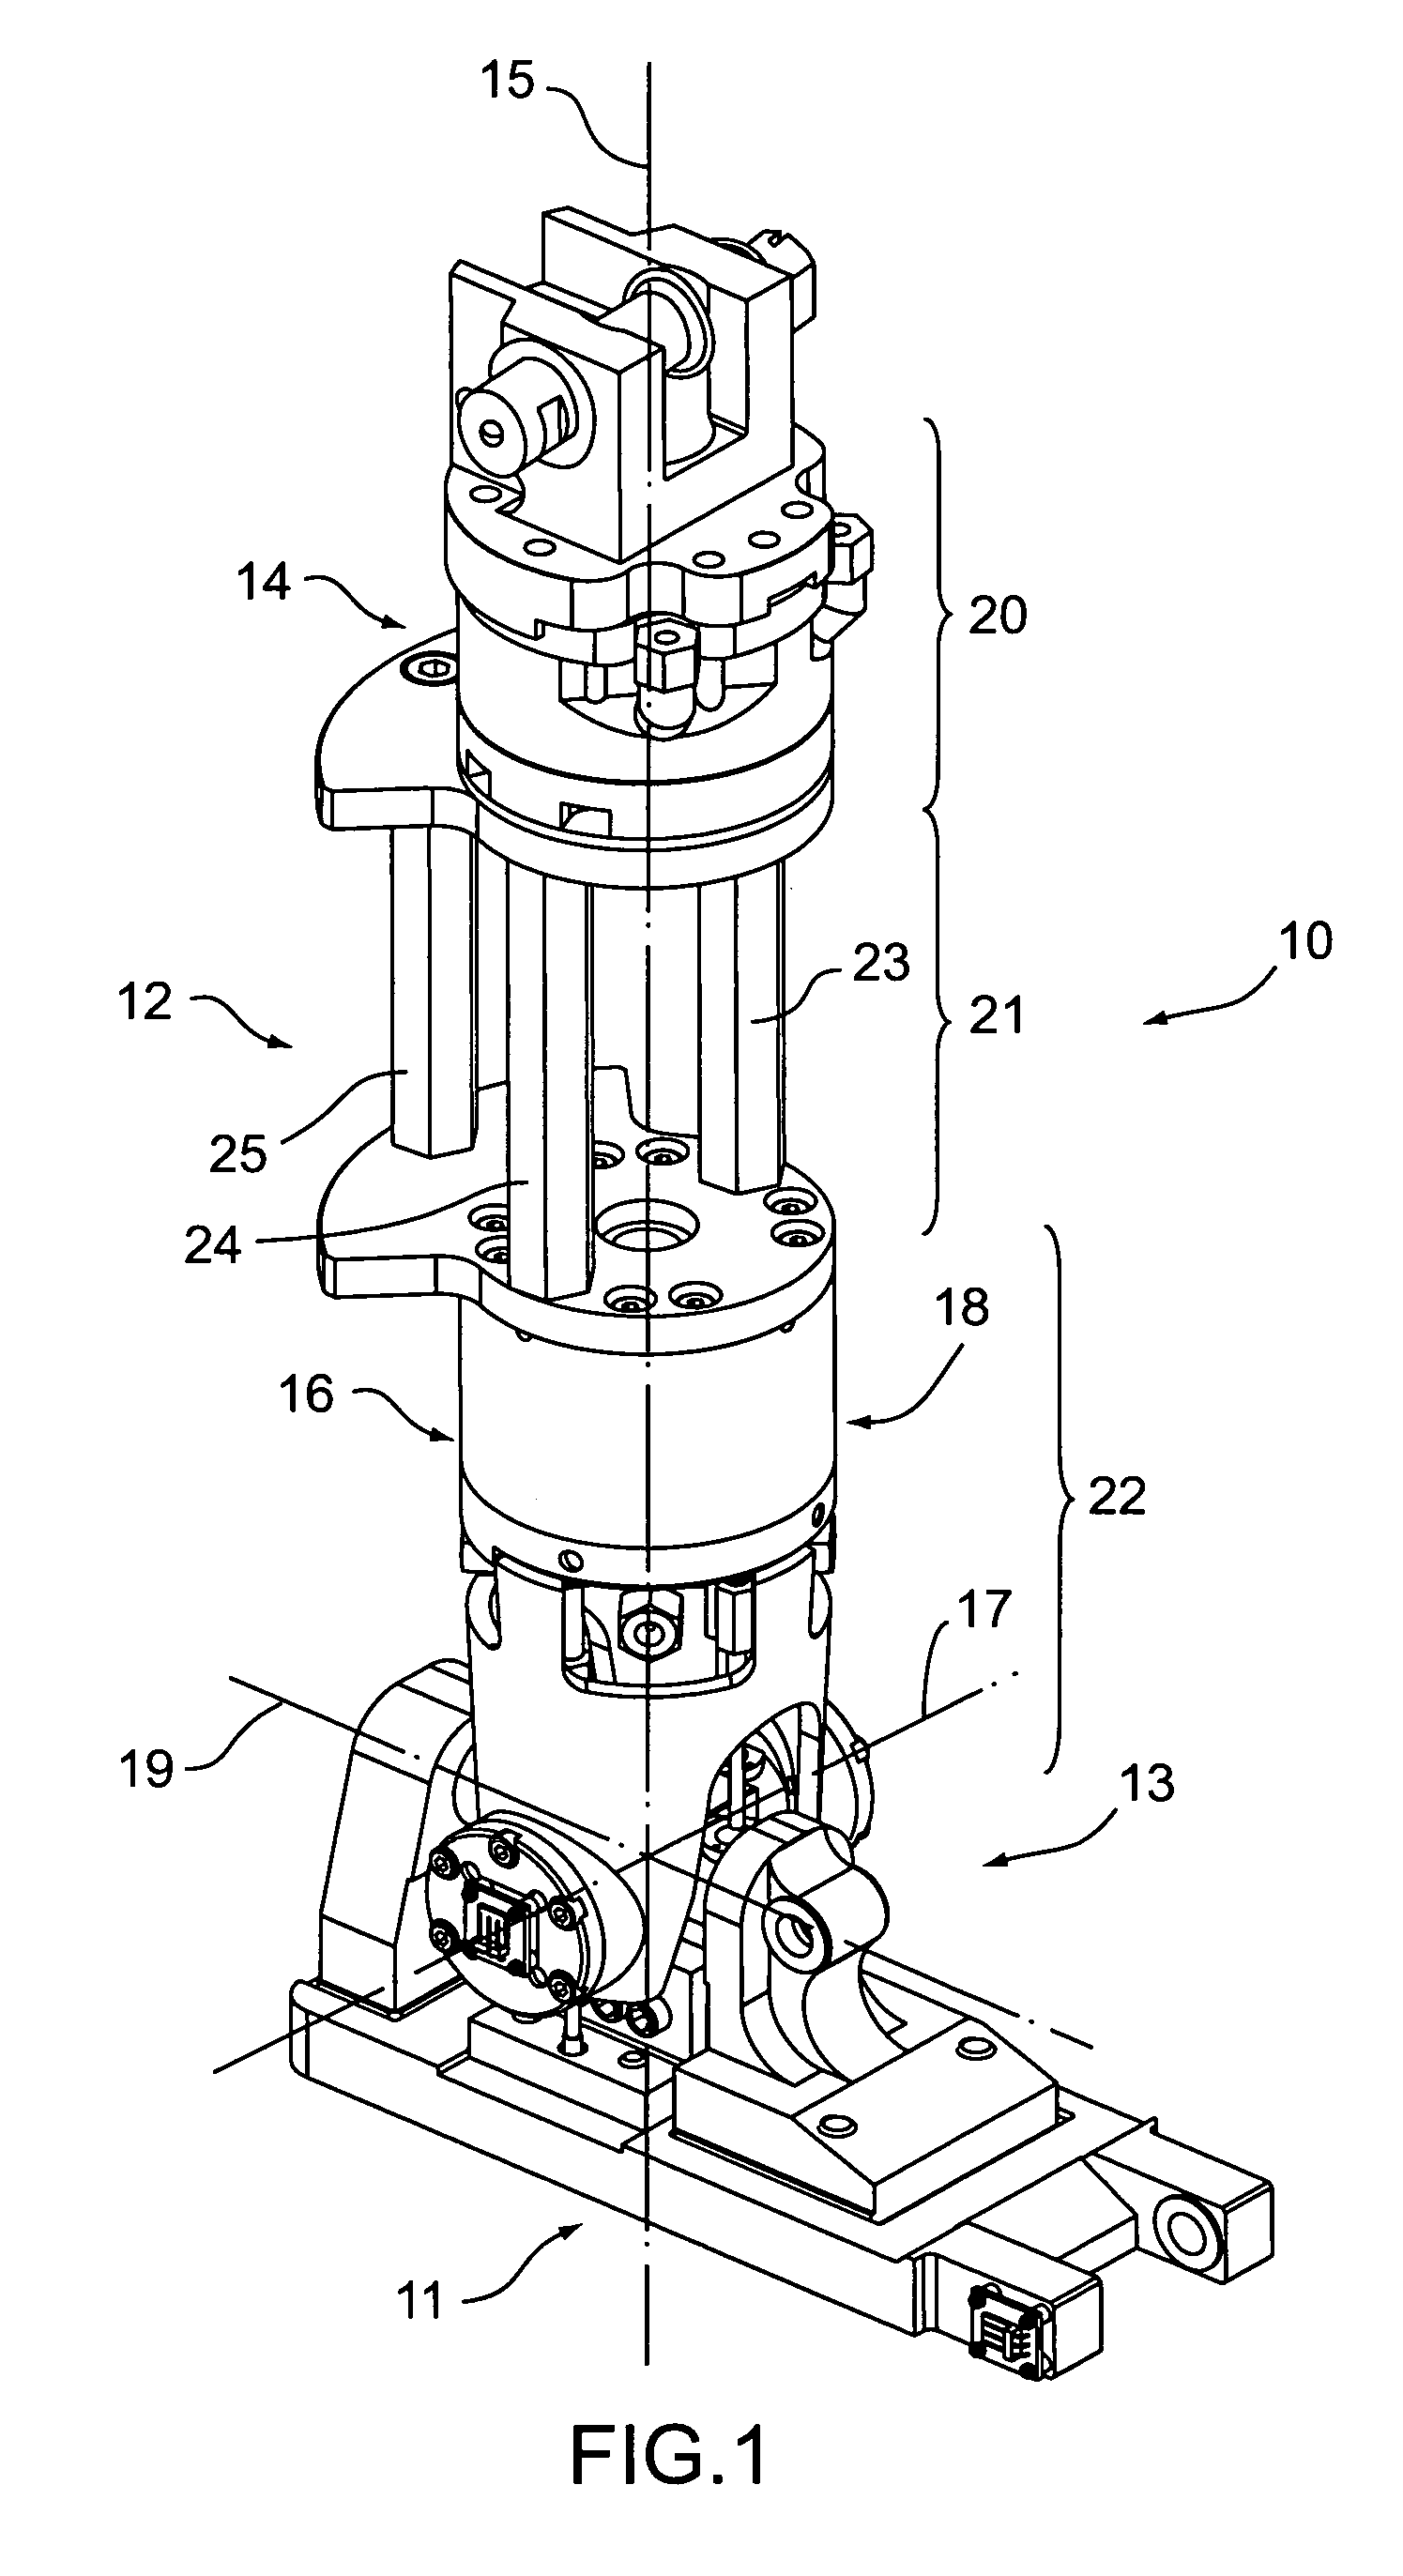
Inventors: ALFAYAD Samer, BEN OUEZDOU Fathi, NAMOUN Fayçal
Published: 12/11/2009 – WO2009135694A1 (US9327785B2, EP2293905B1, JP5754028B2, ES2735504T3)
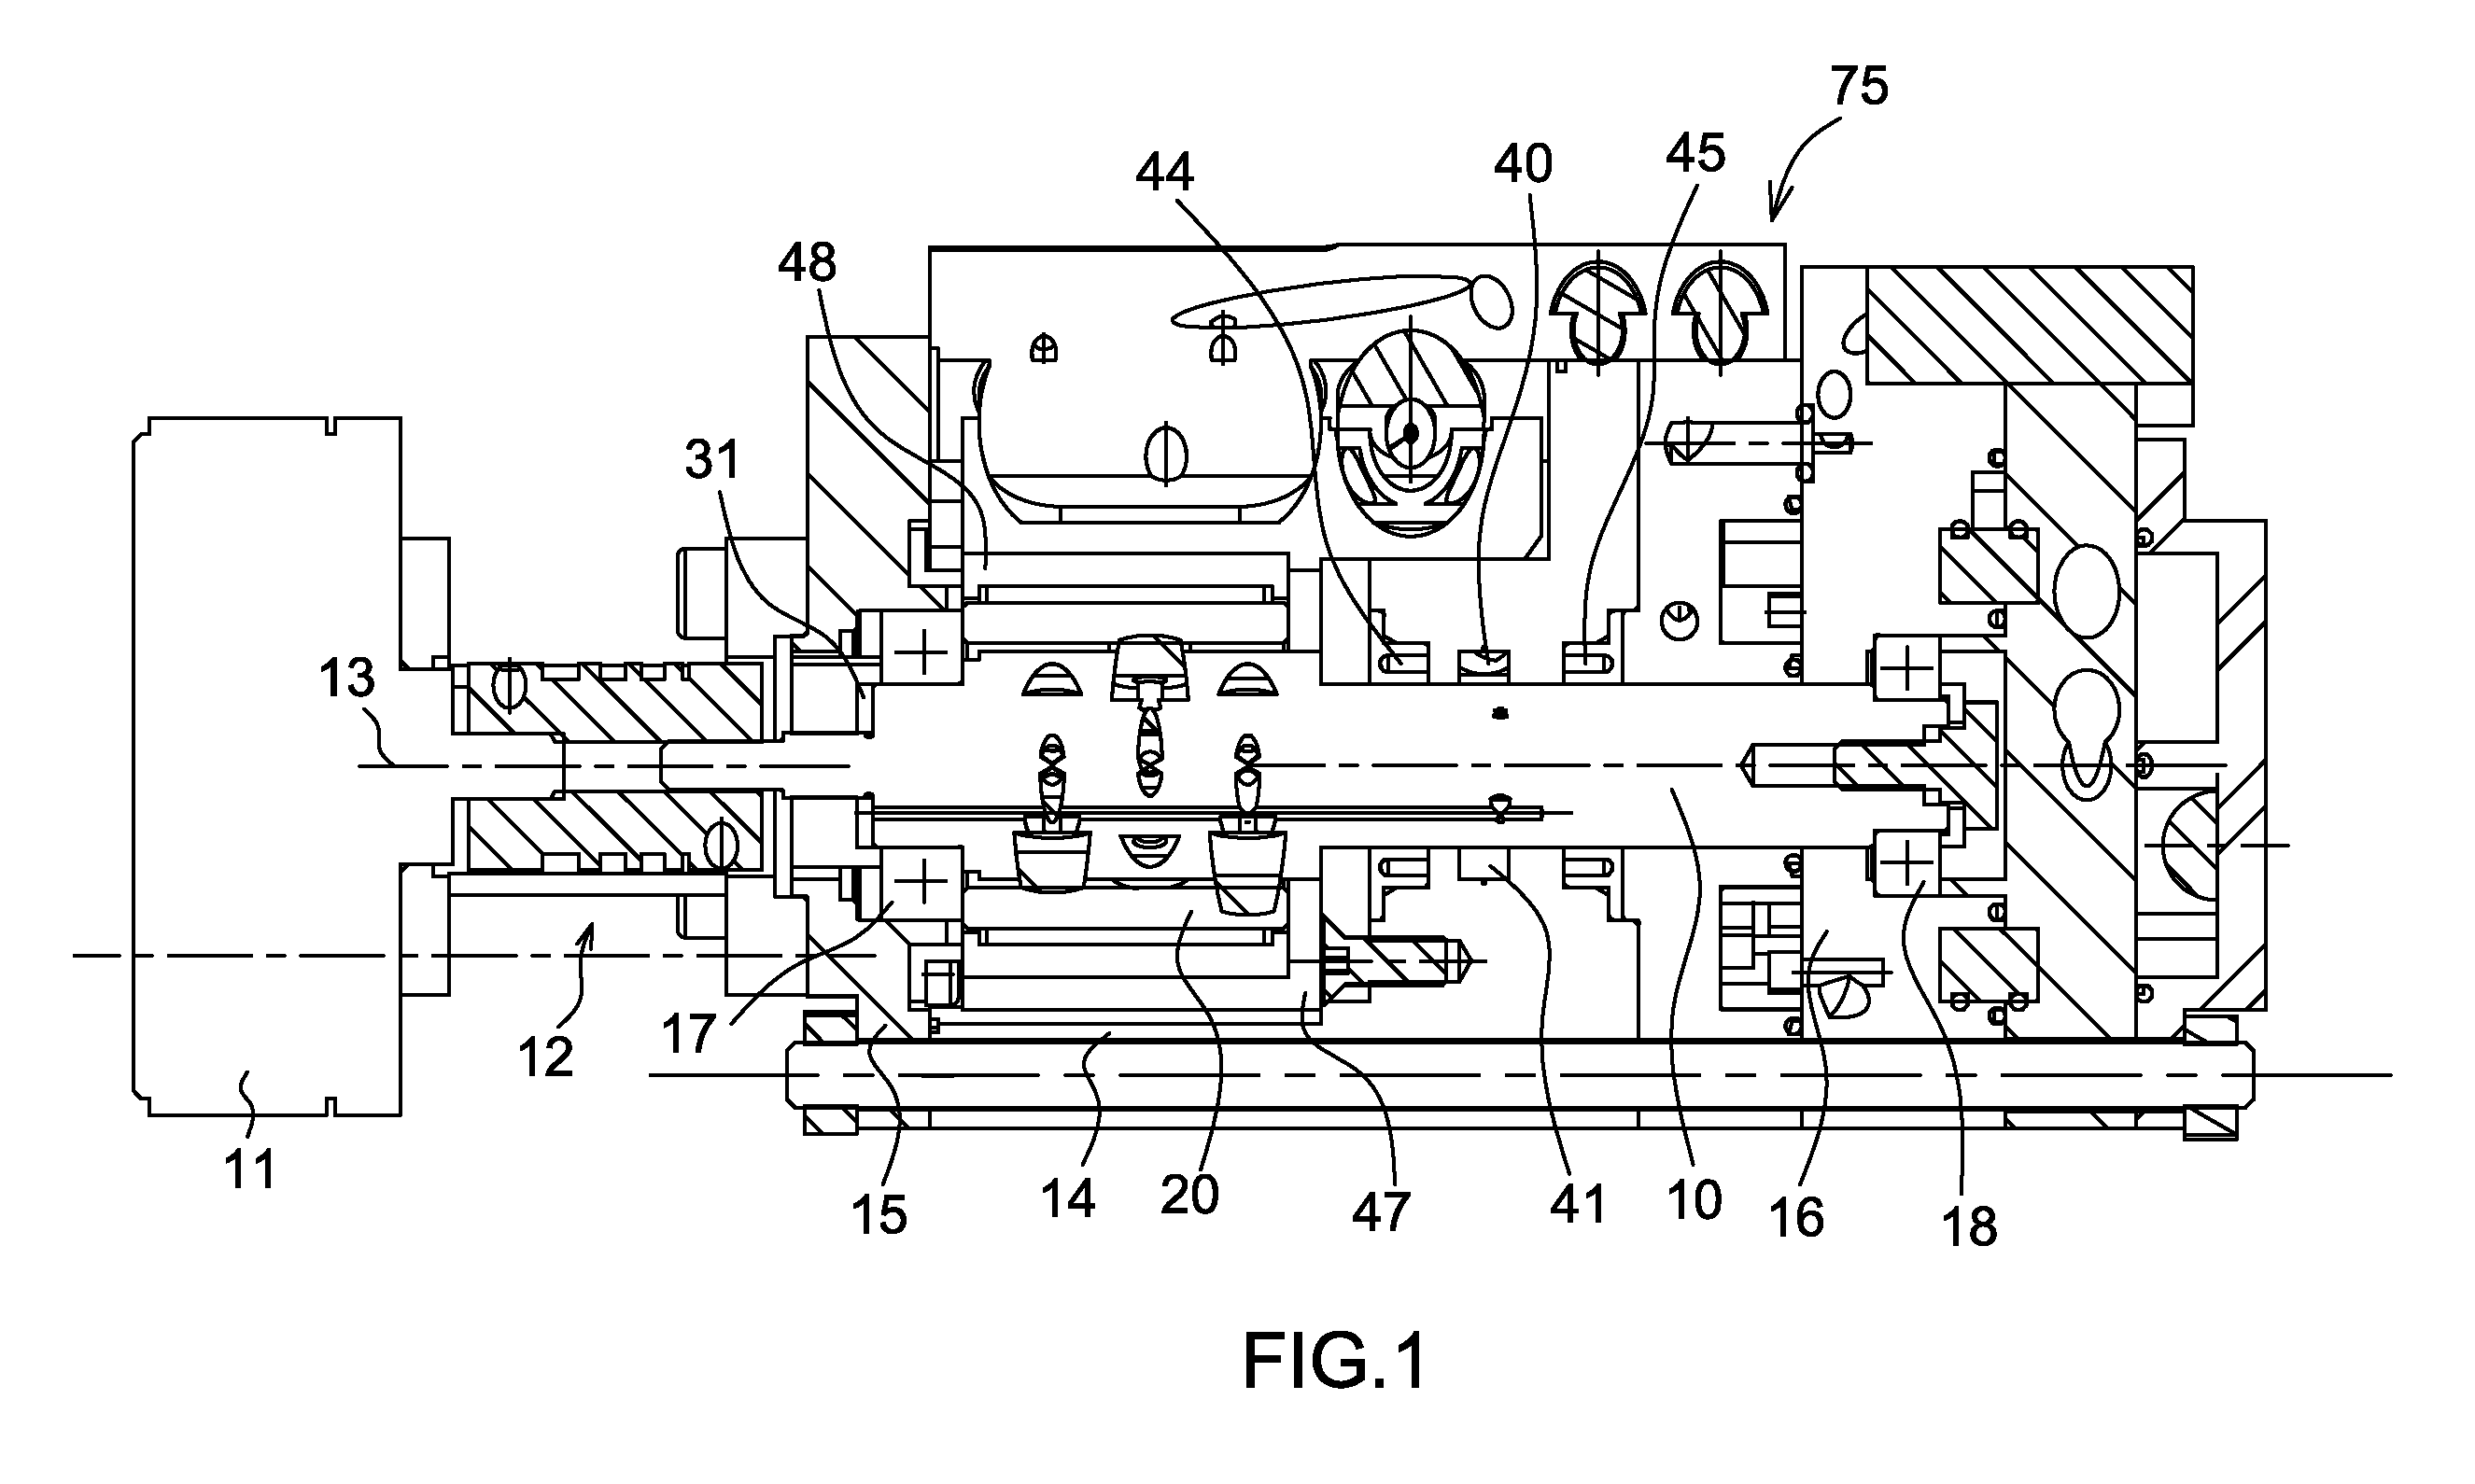
Inventors: ALFAYAD Samer, BEN OUEZDOU Fathi, NAMOUN Fayçal
Published: 1/10/2009 – WO2009118366A1 (US8,734,123B2, EP2268921B1, CN102027234B, JP5613946B2, KR101729785B1, MY159090A, PL2268921, CA2719843, SG2010070548, FR2929347)
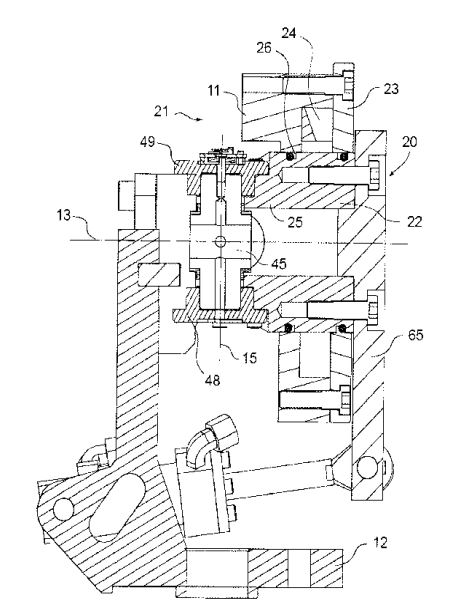
Inventors: ALFAYAD Samer, BEN OUEZDOU Fathi, NAMOUN Fayçal
Published: 2011 – FR2931718A1 (Ankle) and FR2931718B1 (Hip), INPI France
PUBLICATIONS
A selection of recent work in humanoid systems, robotic actuation and assistive technologies.
Explore all publications on Google ScholarTEACHING & LEADERSHIP
Research and education meet in hands-on mechatronics programs, interdisciplinary platforms and supervision of emerging researchers.
Academic Director of the international Master’s program at Université Paris-Saclay. The program prepares students for careers in academia and industry in mechatronics, machine learning, computer vision, and intelligent systems.
Co-creator of the international Master’s program at Université Paris-Saclay, developed with Prof. H. Tabia. The program provides advanced training in mechanical and electrical engineering and prepares students for progression to the M2 level.
Supervising doctoral research across robotics, mechatronics and assistive technologies.
Co-founder of KALYSTA, a startup formed to bring advanced mechatronic technologies into industrial use.
DOCTORAL SUPERVISION
IN THE LAB
Moments with the researchers and doctoral students behind the work.
CONTACT
Research partnerships, academic collaboration and speaking invitations.
IBISC Laboratory
Université d’Évry – Paris-Saclay
Évry-Courcouronnes, France